

Run an Evaluation with Recorded Variations#
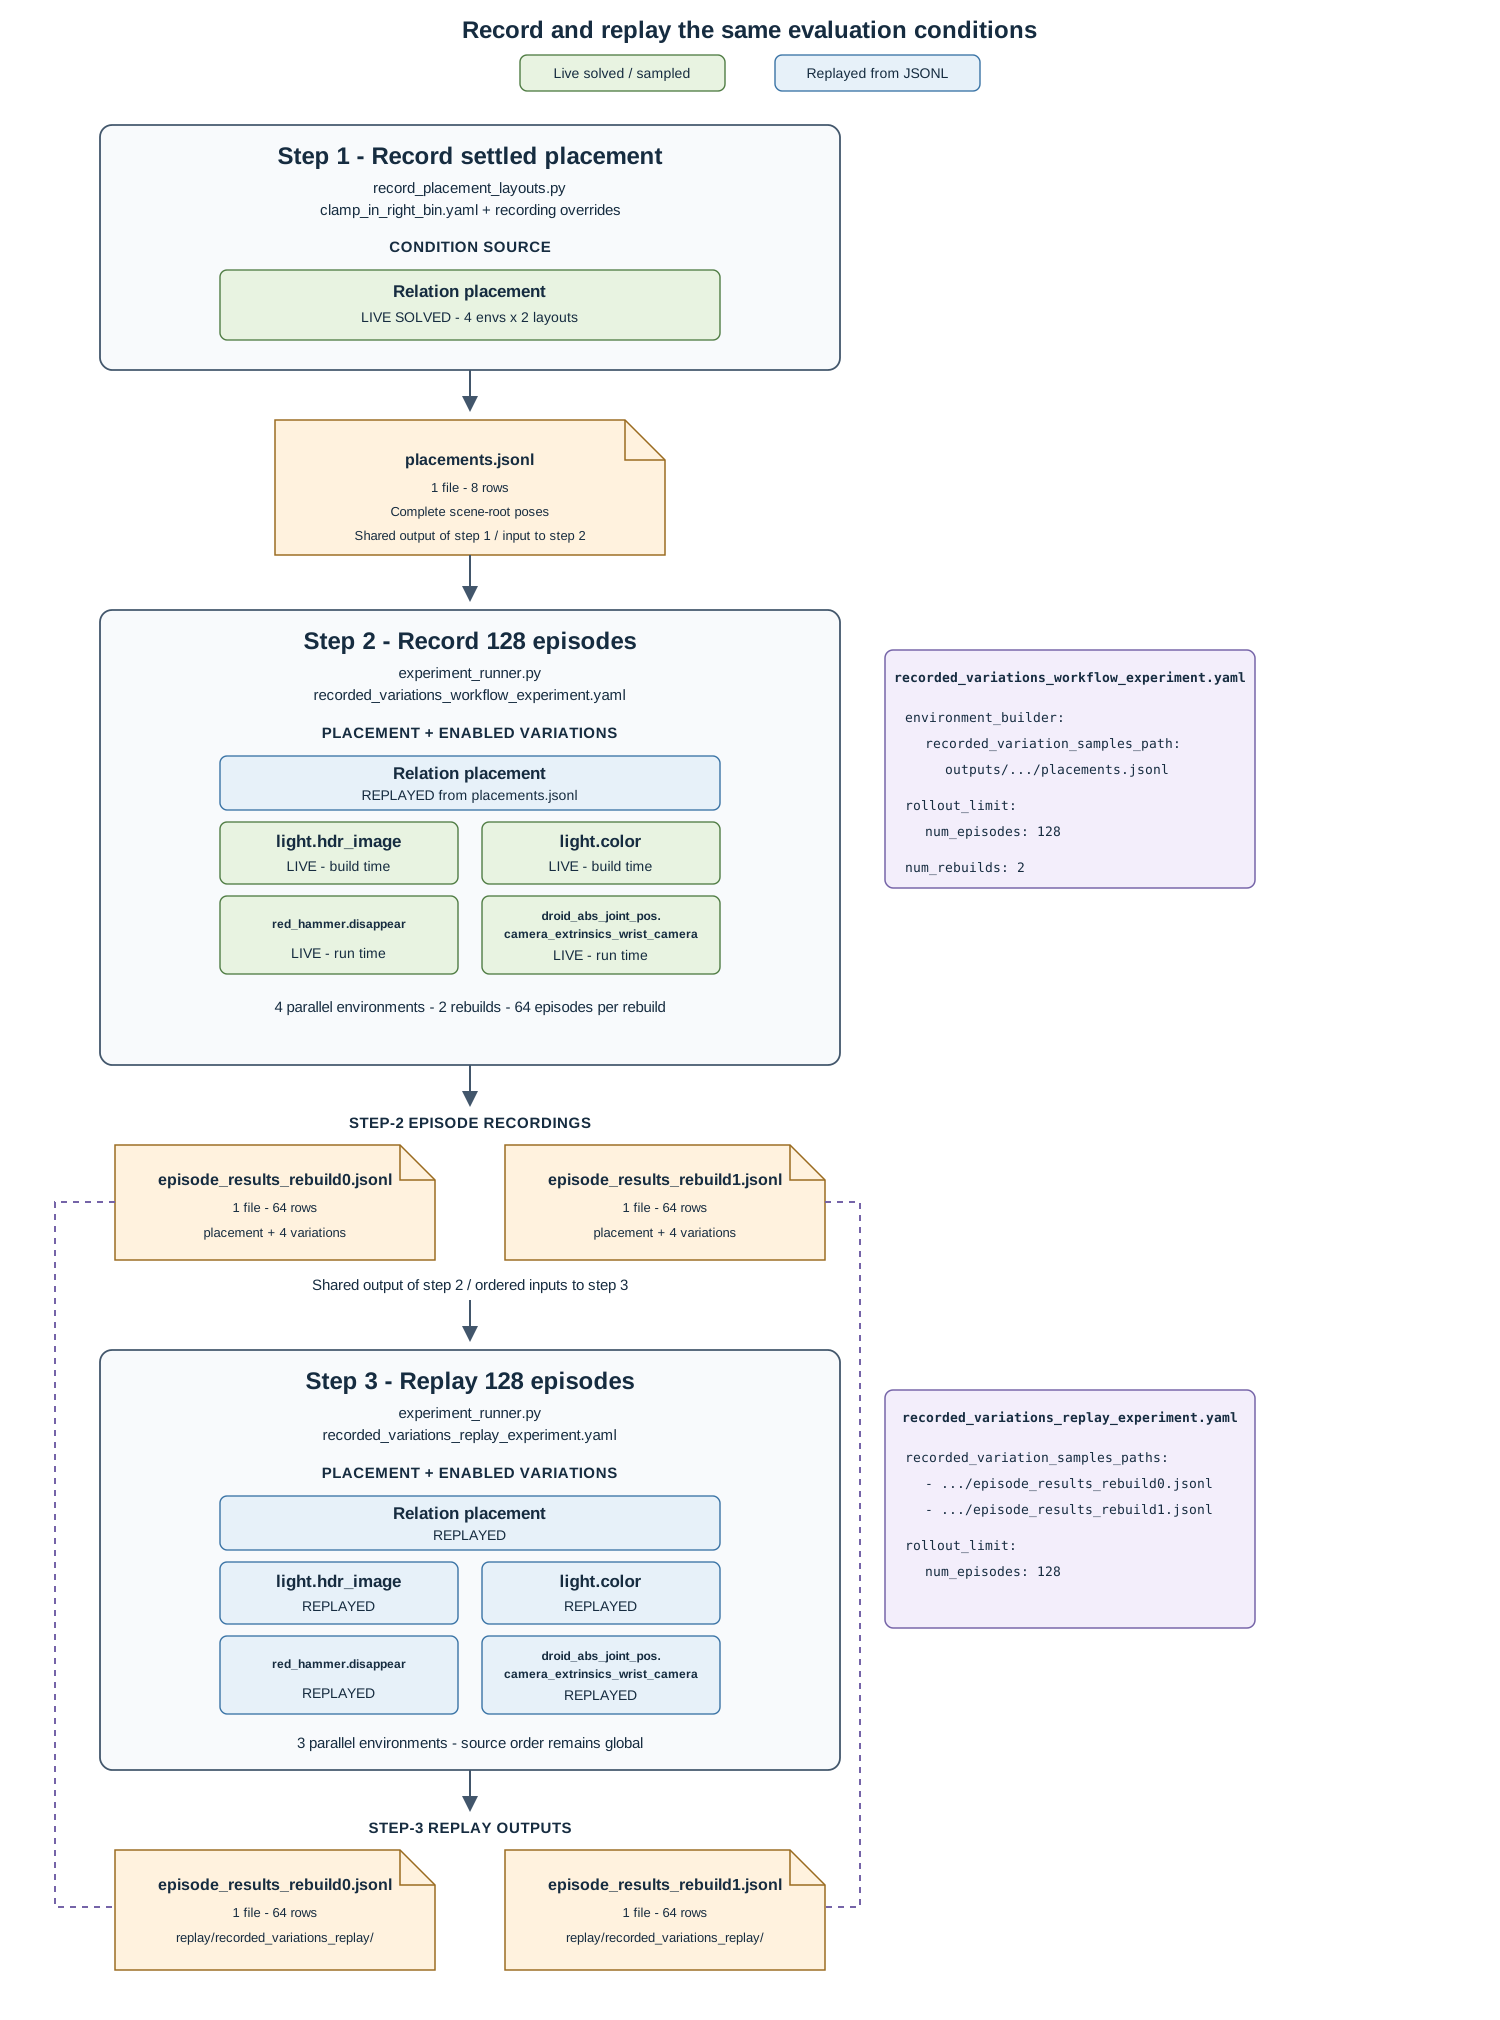
Recorded variations let an evaluation reproduce the same placement, lighting,
object-presence, and camera conditions with a different number of parallel
environments. This workflow uses the clamp_in_right_bin graph environment,
whose standard episode timeout is 70 seconds, and the local zero-action policy.
The workflow has three stages:
record eight settled placement layouts;
run 128 episodes across two rebuilds while recording all enabled variations;
replay the two 64-row recordings in three environments and match each variation payload to its indexed source row.
The generated JSONL files stay below outputs/recorded_variations_workflow
and are not source files.
Record Settled Placement Layouts#
From the repository root, record eight layouts that pass the configured post-physics checks:
python isaaclab_arena/scripts/record_placement_layouts.py \
  env_spec=isaaclab_arena_environments/robolab/tasks/clamp_in_right_bin.yaml \
  output=outputs/recorded_variations_workflow/placements.jsonl \
  num_envs=4 env_spacing=2 layouts_per_env=2 \
  min_layouts=8 max_batches=5 seed=42 presets=physx \
  settle.num_steps=120 \
  settle.validators.pose_shift.max_translation_m=0.015 \
  --device cuda:0
The verified run accepted all eight requested layouts. Each output row records
the complete scene-root poses under the top-level placement key.
Record a 128-Episode Evaluation#
Note
To make steps 2 and 3 complete faster, temporarily edit
isaaclab_arena_environments/robolab/tasks/clamp_in_right_bin.yaml and
change episode_length_s from 70.0 to 1.0. Keep the one-second
timeout through both recording and replay.
The maintained Experiment Definition configures four parallel environments,
the zero-action policy, two rebuilds, and 128 total episodes. Both rebuilds
load the eight-row placement recording through
environment_builder.recorded_variation_samples_path; the replay scheduler
wraps as needed.
The total budget is split evenly, so each rebuild records 64 episodes:
# Copyright (c) 2026, The Isaac Lab Arena Project Developers (https://github.com/isaac-sim/IsaacLab-Arena/blob/main/CONTRIBUTORS.md).
# All rights reserved.
#
# SPDX-License-Identifier: Apache-2.0

runs:
  recorded_variations:
    environment:
      type: isaaclab_arena_environments/robolab/tasks/clamp_in_right_bin.yaml
      enable_cameras: true
    environment_builder:
      num_envs: 4
      presets: PHYSX
      recorded_variation_samples_path: outputs/recorded_variations_workflow/placements.jsonl
    policy:
      type: zero_action
    rollout_limit:
      num_episodes: 128
    num_rebuilds: 2
    variations:
      light.hdr_image.enabled: true
      light.color.enabled: true
      red_hammer.disappear.enabled: true
      droid_abs_joint_pos.camera_extrinsics_wrist_camera.enabled: true
It enables two build-time variations:
light.hdr_imagelight.color
It also enables two run-time variations:
red_hammer.disappearfor a distractor that is not part of the task;droid_abs_joint_pos.camera_extrinsics_wrist_camera.
The placement recording supplies the scene-level relation-placement samples. Other enabled variations are sampled live and recorded in each episode result.
Run the Experiment:
python isaaclab_arena/evaluation/experiment_runner.py \
  --experiment_config \
    isaaclab_arena_environments/experiment_configs/placement_record_replay/recorded_variations_workflow_experiment.yaml \
  --viz none \
  --experiment_output_directory \
    outputs/recorded_variations_workflow/record
The canonical recordings are written to:
outputs/recorded_variations_workflow/record/recorded_variations/episode_results_rebuild0.jsonl
outputs/recorded_variations_workflow/record/recorded_variations/episode_results_rebuild1.jsonl
A complete run writes exactly 64 rows to each file, for 128 episodes total. Zero action does not solve the task; task failure is expected and does not indicate an execution failure.
Replay with Three Parallel Environments#
The replay Experiment Definition lists the two step-2 episode recordings, configures three parallel environments, and runs 128 total episodes. The two-file replay list supplies one file per rebuild, so each rebuild replays all 64 rows:
# Copyright (c) 2026, The Isaac Lab Arena Project Developers (https://github.com/isaac-sim/IsaacLab-Arena/blob/main/CONTRIBUTORS.md).
# All rights reserved.
#
# SPDX-License-Identifier: Apache-2.0

runs:
  recorded_variations_replay:
    environment:
      type: isaaclab_arena_environments/robolab/tasks/clamp_in_right_bin.yaml
      enable_cameras: true
    environment_builder:
      num_envs: 3
      presets: PHYSX
    recorded_variation_samples_paths:
      - outputs/recorded_variations_workflow/record/recorded_variations/episode_results_rebuild0.jsonl
      - outputs/recorded_variations_workflow/record/recorded_variations/episode_results_rebuild1.jsonl
    policy:
      type: zero_action
    rollout_limit:
      num_episodes: 128
    variations:
      light.hdr_image.enabled: true
      light.color.enabled: true
      red_hammer.disappear.enabled: true
      droid_abs_joint_pos.camera_extrinsics_wrist_camera.enabled: true
Run the replay:
python isaaclab_arena/evaluation/experiment_runner.py \
  --experiment_config \
    isaaclab_arena_environments/experiment_configs/placement_record_replay/recorded_variations_replay_experiment.yaml \
  --viz none \
  --experiment_output_directory \
    outputs/recorded_variations_workflow/replay
Verify the episode count, source-index coverage, and variation payloads:
python - <<'PY'
import json
from pathlib import Path

root = Path("outputs/recorded_variations_workflow")
for rebuild_index in range(2):
    filename = f"episode_results_rebuild{rebuild_index}.jsonl"
    source_path = root / "record/recorded_variations" / filename
    replay_path = root / "replay/recorded_variations_replay" / filename
    source = [json.loads(line) for line in source_path.read_text().splitlines()]
    replay = [json.loads(line) for line in replay_path.read_text().splitlines()]

    assert len(source) == len(replay) == 64
    source_indices = [row["replay_source_record_index"] for row in replay]
    assert sorted(source_indices) == list(range(len(source)))
    for replay_row in replay:
        index = replay_row["replay_source_record_index"]
        source_row = source[index]
        assert replay_row["placement"] == source_row["placement"]
        assert replay_row["variations"] == source_row["variations"]
print("Matched all 128 recorded placement and variation rows.")
PY
A complete replay writes exactly 64 rows per rebuild. Every replayed row’s
placement and variations mappings should exactly match the corresponding
indexed source row. The replay_source_record_index values should collectively
cover every source row exactly once; their output order may differ. Episode metadata
such as env_id and timestamp can differ because the replay uses a different
parallelization.
The matching replay payload contains:
the relation-placement scene-root poses under
placement;HDR selection, light color, red-hammer presence, and wrist-camera extrinsics under
variations.
This verifies that recorded variation order is independent of the number of parallel simulation environments.
Note
After completing the workflow, discard the temporary timeout edit by
restoring episode_length_s in
isaaclab_arena_environments/robolab/tasks/clamp_in_right_bin.yaml to
70.0. The one-second timeout is only for this sample workflow and should
not be retained for normal evaluations.