

Record and Replay Clutter Layouts#
ClutterOn places objects above a support so physics can settle them into a
reusable layout. Use record_placement_layouts.py to save accepted root poses
to JSONL, then replay those poses without solving or settling again.
Complete Installation and run the commands below from the
repository root. Recording can run headless: replace render=true --viz kit
with render=false --viz none. The interactive replay commands below require
a display; use the Experiment workflow in Record and Replay Placement Poses for headless replay.
Tool Clutter on a Table#
The franka_three_hammers_and_clamp_no_task environment drops three hammers
and a clamp onto a fixed table.
Record#
python isaaclab_arena/scripts/record_placement_layouts.py \
    env_spec=isaaclab_arena_environments/clutter/franka_three_hammers_and_clamp_no_task.yaml \
    output=outputs/clutter/tools_on_table.jsonl \
    num_envs=4 min_layouts=10 layouts_per_env=4 max_batches=15 seed=42 \
    settle.num_steps=480 \
    +settle.validators.support_containment.minimum_resting_heights_m.office_table_background=0.5306 \
    render=true --device cpu --viz kit
The table has a beveled top, so the command supplies its local-Z top height.
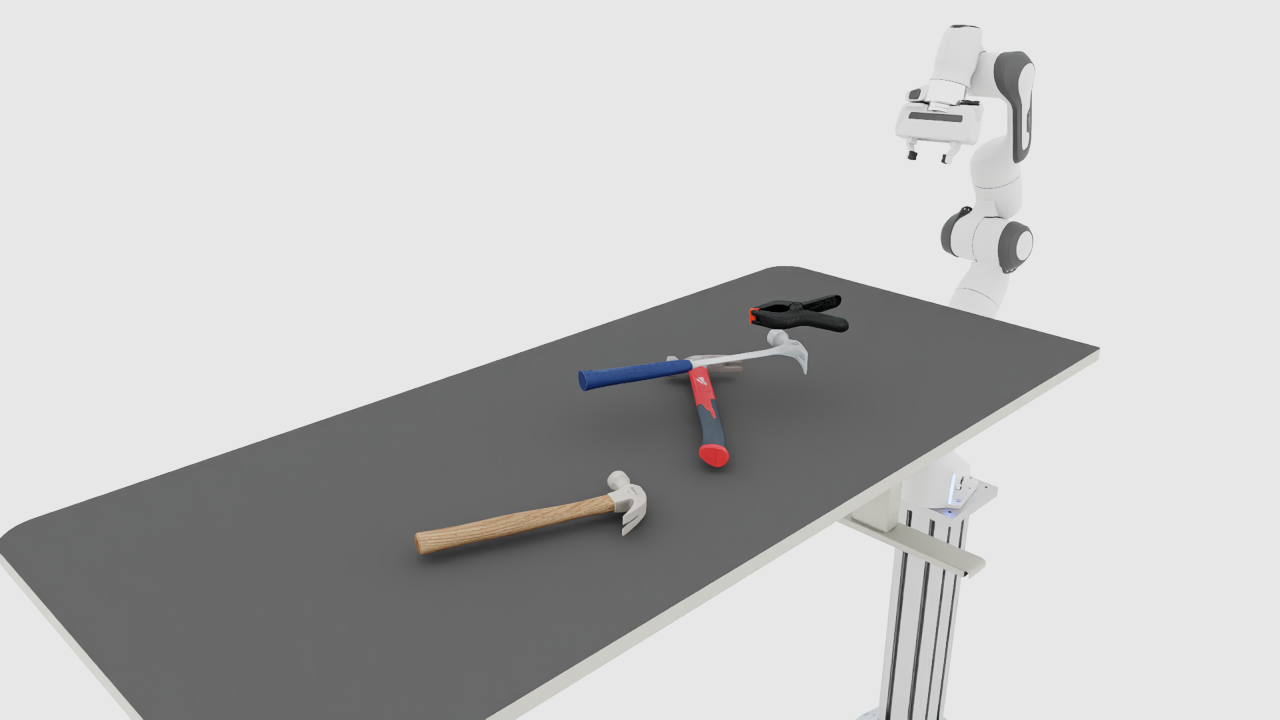
Release poses selected by the placement solver.#
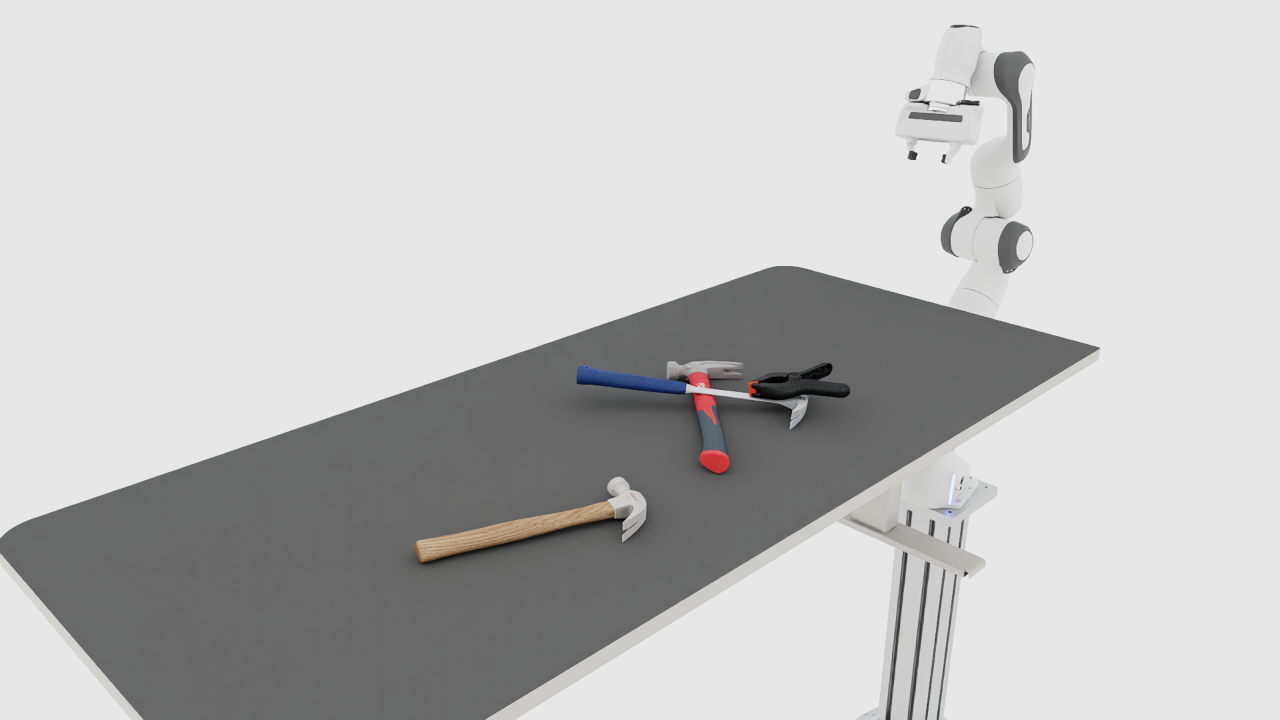
The recorded root poses after physics settling.#
Replay#
python isaaclab_arena/scripts/environment_runner.py \
    --env_spec isaaclab_arena_environments/clutter/franka_three_hammers_and_clamp_no_task.yaml \
    --placement_layouts outputs/clutter/tools_on_table.jsonl \
    --num_envs 1 --device cpu --viz kit
Cube Clutter in a Container#
The franka_three_cubes_in_bowl_no_task environment drops three cubes into a
fixed YCB bowl.
Record#
python isaaclab_arena/scripts/record_placement_layouts.py \
    env_spec=isaaclab_arena_environments/clutter/franka_three_cubes_in_bowl_no_task.yaml \
    output=outputs/clutter/three_cubes_in_bowl.jsonl \
    num_envs=1 min_layouts=1 layouts_per_env=5 max_batches=5 seed=42 \
    settle.num_steps=480 \
    +settle.validators.support_containment.minimum_resting_heights_m.bowl=-0.025 \
    render=true --device cpu --viz kit
The minimum resting height is the bowl floor in the bowl’s local frame. It lets the cubes settle below the rim while still rejecting objects that fall through the bowl.
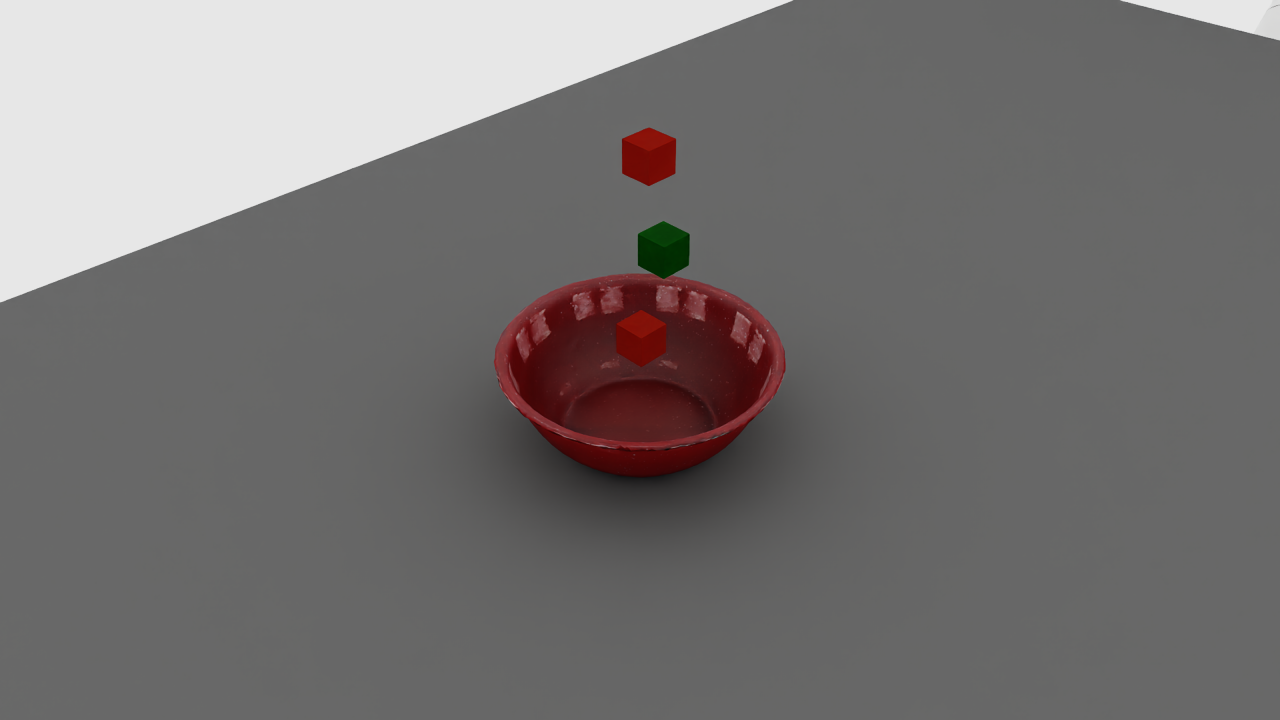
Release poses above the bowl rim.#
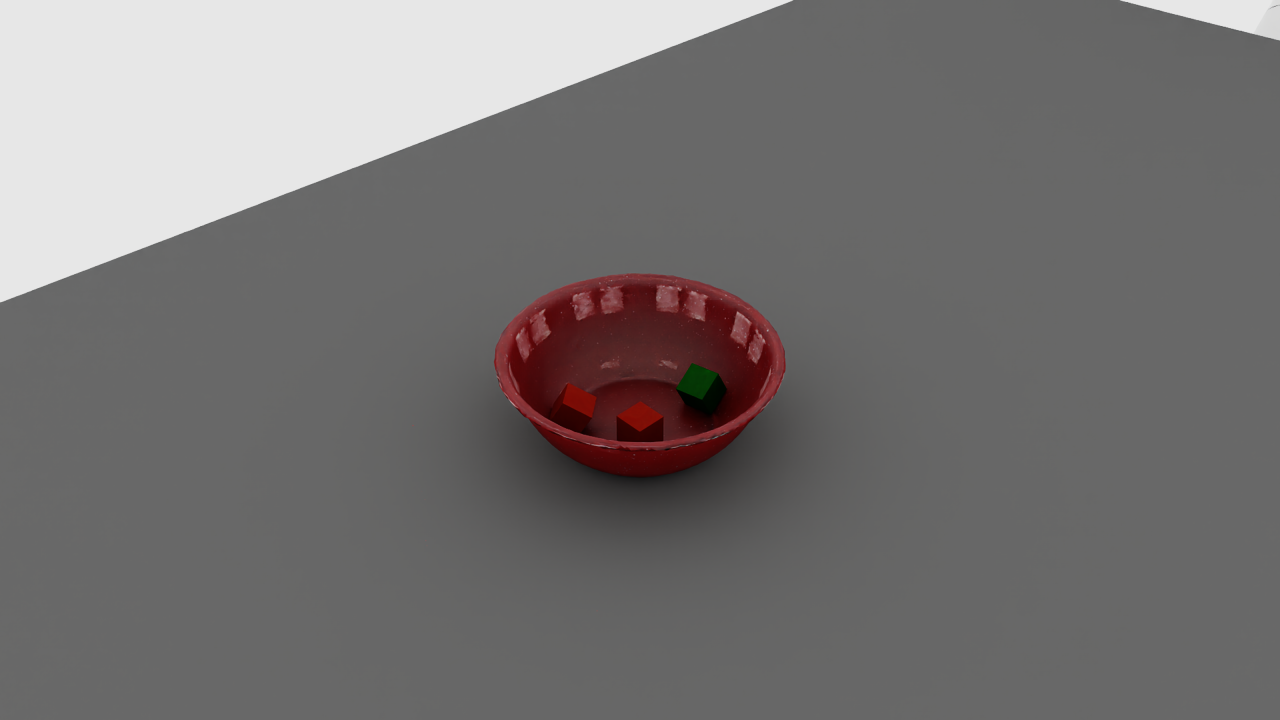
The recorded root poses after physics settling.#
Replay#
python isaaclab_arena/scripts/environment_runner.py \
    --env_spec isaaclab_arena_environments/clutter/franka_three_cubes_in_bowl_no_task.yaml \
    --placement_layouts outputs/clutter/three_cubes_in_bowl.jsonl \
    --num_envs 1 --device cpu --viz kit
Recording and Replay Notes#
Choose a new output path for each recording; existing JSONL files are not overwritten. Each line stores one accepted layout. If the batch budget ends early, any accepted layouts are still written; no file is created when none pass.
Both examples use NoTask, so interactive replay loads the first saved layout
and does not trigger episode resets. Close the viewer to exit. For policy
evaluation replay, use the Experiment workflow in Record and Replay Placement Poses.
See Placement Validation for clutter acceptance checks, container-height settings and rejection guidance. See Relations and Strategies for the JSONL format and layout selection across resets and parallel environments.