

Data Generation#
This workflow covers annotating and generating the demonstration dataset using Isaac Lab Mimic.
Prepare the Arena runtime from the repository root, using either a native uv environment or the
base Docker container (see Installation for the full setup):
uv sync --extra dev
source .venv/bin/activate
export OMNI_KIT_ACCEPT_EULA=YES ACCEPT_EULA=Y
./docker/run_docker.sh
Step 1: Annotate Demonstrations#
This step describes how to annotate the demonstrations recorded in the preceding step so they can be used by Isaac Lab Mimic. For more details on Mimic annotation, see the Isaac Lab Mimic documentation.
To skip this step, you can download the pre-annotated dataset from Hugging Face as described below.
Download Pre-annotated Dataset (skip annotation step)
These commands can be used to download the pre-annotated dataset, such that the annotation step can be skipped.
To download run:
hf download \
   nvidia/Arena-G1-Loco-Manipulation-Task \
   arena_g1_loco_manipulation_dataset_annotated.hdf5 \
   --repo-type dataset \
   --revision arena_v0.2_lab_v3.0 \
   --local-dir $DATASET_DIR
Run from the repository root with DATASET_DIR set to the directory used in
Teleoperation Data Collection. Keep the task,
object, embodiment and physics device consistent with the recording.
To start manual annotation, run:
python submodules/IsaacLab/scripts/imitation_learning/isaaclab_mimic/annotate_demos.py \
  --viz kit \
  --device cpu \
  --input_file $DATASET_DIR/arena_g1_loco_manipulation_dataset_recorded.hdf5 \
  --output_file $DATASET_DIR/arena_g1_loco_manipulation_dataset_annotated.hdf5 \
  --mimic \
  --external_callback isaaclab_arena.environments.isaaclab_interop.environment_registration_callback \
  --task galileo_g1_locomanip_pick_and_place \
  env.actions.g1_action.use_p_control=false
The final override keeps the recorded navigation commands during annotation. Step 2 below uses the navigation controller to generate new demonstrations.
Mark the subtask boundaries
Click inside the Isaac Sim viewport before using the keyboard. These keys are read by the simulation window, not the terminal:
N: begin or resume playback.B: pause playback.S: mark the next subtask boundary at the current frame.Q: skip the entire episode without exporting it.
Annotation has three passes: right arm, left arm, then body. The
entire episode replays on each pass; mark only the named arm or body.
The terminal identifies the pass as eef "right", eef "left" or eef "body".
Press N to begin each pass, then S once at each boundary below, in order.
You can pause with B, mark with S, then resume with N.
Pass |
Signal |
When to press |
|---|---|---|
Right arm |
|
When the right arm finishes waiting and starts reaching for the box. |
Right arm |
|
When grasping and carrying finish, just before the right arm starts placing the box in the bin. |
Left arm |
|
When the left arm finishes waiting and starts reaching for the box. |
Left arm |
|
When grasping and carrying finish, just before the left arm starts placing the box in the bin. |
Body |
|
When the robot reaches the pickup position in front of the box. |
Body |
|
When the robot finishes turning toward the bin after picking up the box. |
Body |
|
When the robot stops walking at the bin, before it squats to place the box. |
Mark two boundaries per arm and three for the body. Let each replay finish after marking them. The final subtask ends with the episode and needs no mark.
Each press prints Marked a subtask signal at action index: <index>. If you
mistime a mark, press S once more before the replay ends; the wrong count
makes the script replay the pass. To drop the episode instead, press Q.
Check the result
For each exported episode, the output includes:
All 2 subtask signals for eef "right" were annotated.
All 2 subtask signals for eef "left" were annotated.
All 3 subtask signals for eef "body" were annotated.
Exported the annotated episode.
After the last episode, the script prints a summary. For example, a run on five recorded episodes in which one replay failed prints:
Exported 4 (out of 5) annotated episodes.
Successful task completions: 4
Annotation succeeds when at least one episode is exported. Some episodes may be skipped if PhysX non-determinism causes borderline successful trajectories to fail the task during replay.
Important
Do not start Step 2 with zero exported episodes. The script creates the
output file when it starts, replacing any existing file at
--output_file, so the file exists even when every episode fails. Its
existence or size does not mean it contains annotated demonstrations.
Recover the failed annotations below or use the pre-annotated download
above.
Recover from an unsuccessful annotation
Message |
Meaning and next action |
|---|---|
|
Replay succeeded, but the number of marks was wrong. The script clears
the marks for this pass and pauses the retry until you press |
|
The replay failed the task’s success check. The entire episode is
skipped without retrying, even if an earlier pass succeeded. Replaying
the same recorded actions can produce different outcomes, so a few
episodes can fail this way at random. If every episode fails, check
that the command includes |
Skipped exporting the episode due to incomplete subtask annotations also
appears after a failed task replay or after Q; read the preceding message
for the cause.
Skipped episodes remain in the original recorded file.
Step 2: Generate Augmented Dataset#
Isaac Lab Mimic generates additional demonstrations from the annotated demonstrations by applying object and trajectory transformations to introduce data variations.
This step can be skipped by downloading the pre-generated dataset from Hugging Face as described below.
Download Pre-generated Dataset (skip data generation step)
These commands can be used to download the pre-generated dataset, such that the data generation step can be skipped.
hf download \
   nvidia/Arena-G1-Loco-Manipulation-Task \
   arena_g1_loco_manipulation_dataset_generated.hdf5 \
   --repo-type dataset \
   --revision arena_v0.2_lab_v3.0 \
   --local-dir $DATASET_DIR
Generate the dataset:
# Generate 100 demonstrations
python submodules/IsaacLab/scripts/imitation_learning/isaaclab_mimic/generate_dataset.py \
  --enable_cameras \
  --mimic \
  --input_file $DATASET_DIR/arena_g1_loco_manipulation_dataset_annotated.hdf5 \
  --output_file $DATASET_DIR/arena_g1_loco_manipulation_dataset_generated.hdf5 \
  --generation_num_trials 100 \
  --device cpu \
  --external_callback isaaclab_arena.environments.isaaclab_interop.environment_registration_callback \
  --task galileo_g1_locomanip_pick_and_place \
  --object brown_box \
  --embodiment g1_wbc_pink
Data generation takes 1-4 hours depending on your CPU/GPU.
Add --viz kit to visualize during data generation.
Step 3: Validate Generated Dataset (Optional)#
To visualize the data produced, you can replay the dataset using the following command:
Note
Non-determinism may be observed when replaying demonstrations with PhysX because
physics in Isaac Lab is not deterministically reproducible across env.reset()
calls. A demonstration may therefore fail during replay even though it succeeded
during generation; all generated demonstrations remain valid for training.
This dataset was generated using CPU physics, so the replay command uses
--device cpu to reduce device-related differences between generation and replay.
python submodules/IsaacLab/scripts/tools/replay_demos.py \
  --viz kit \
  --device cpu \
  --enable_cameras \
  --dataset_file $DATASET_DIR/arena_g1_loco_manipulation_dataset_generated.hdf5 \
  --external_callback isaaclab_arena.environments.isaaclab_interop.environment_registration_callback \
  --task galileo_g1_locomanip_pick_and_place \
  --object brown_box \
  --embodiment g1_wbc_pink
You should see the robot successfully perform the task.
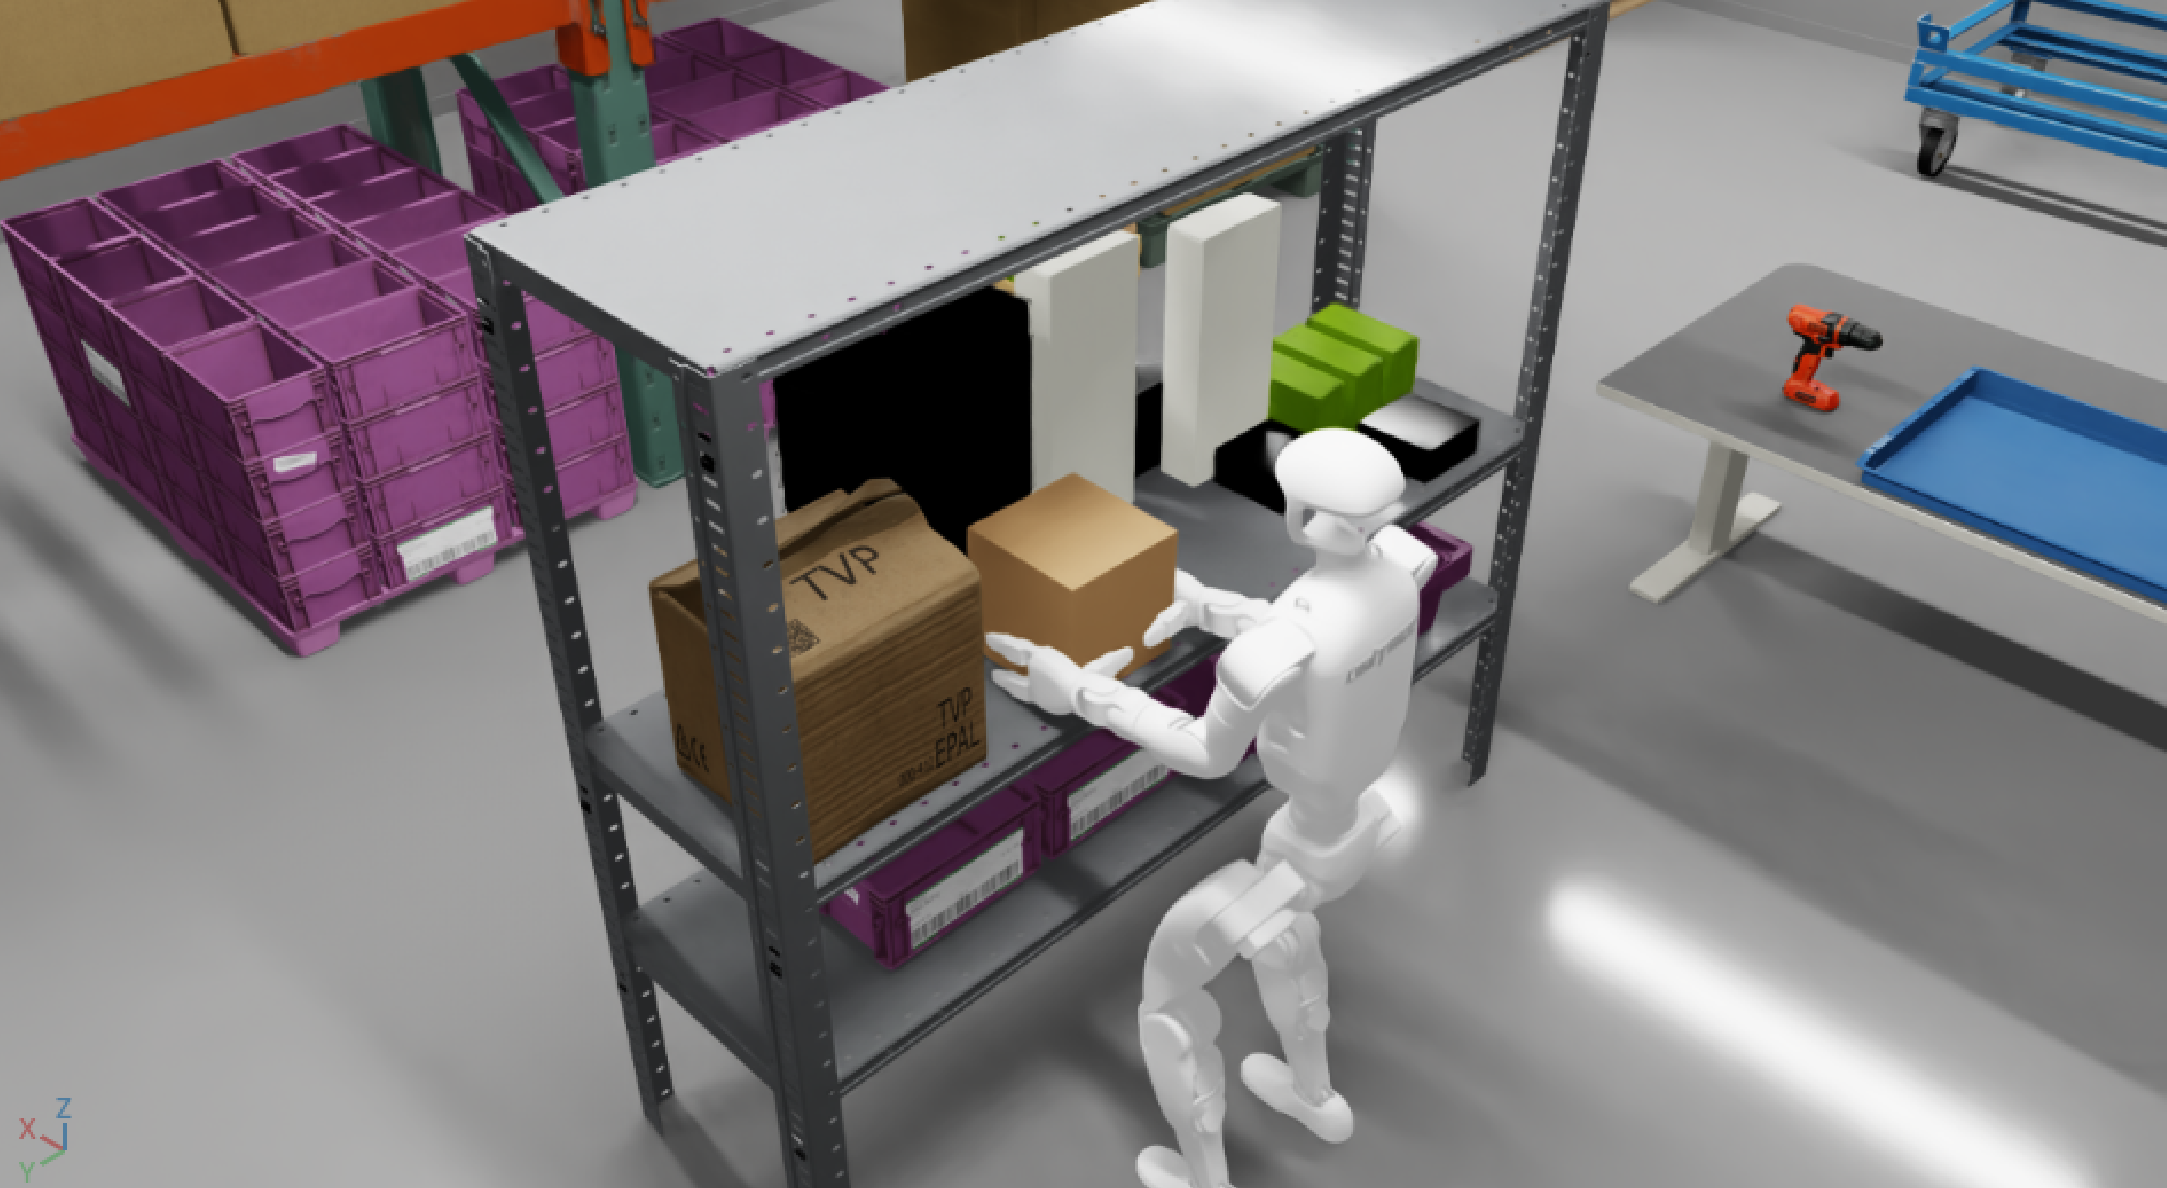
IsaacLab Arena G1 Locomanip Pick and Place Task View#