

Dexsuite Kuka Allegro Lift Task (Newton)#
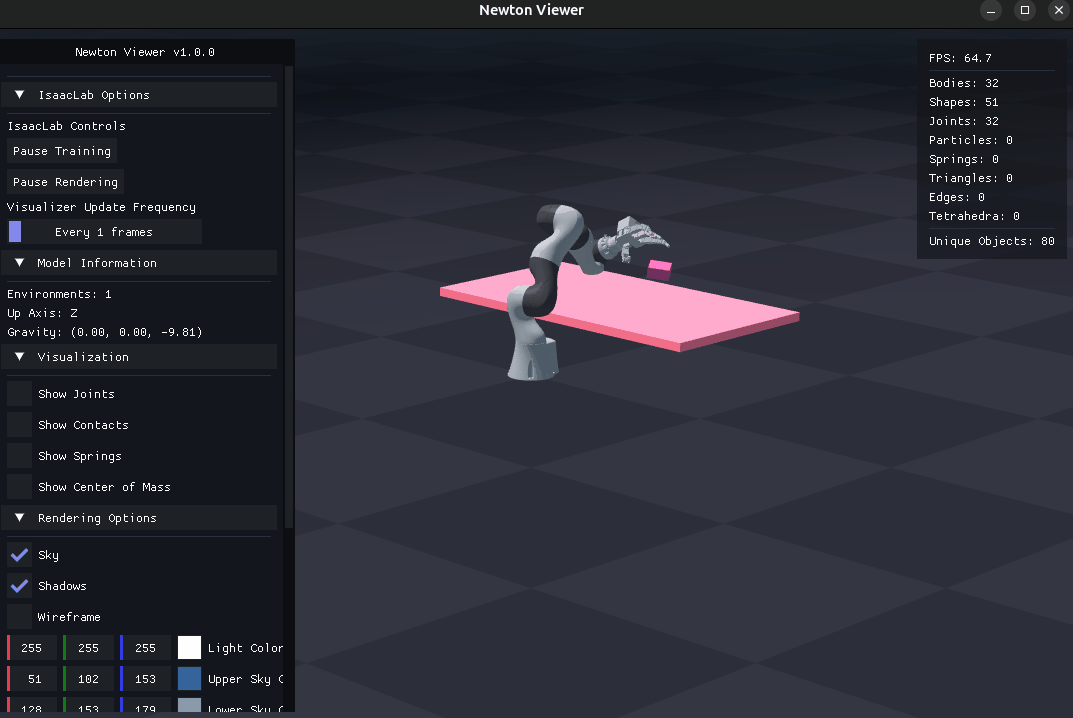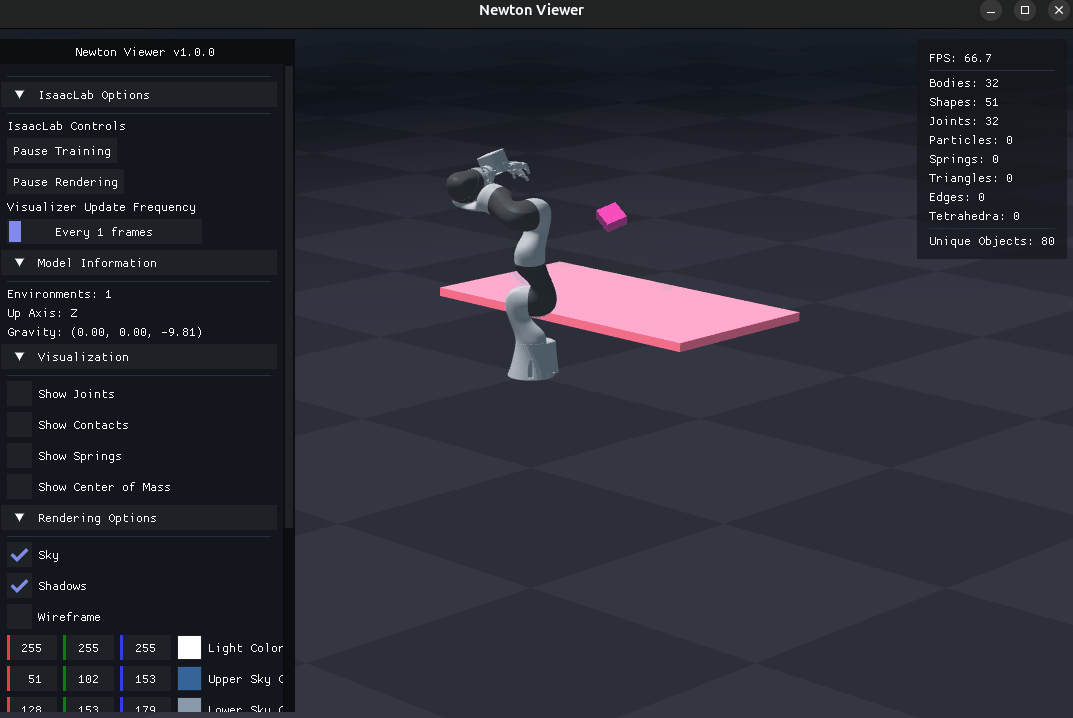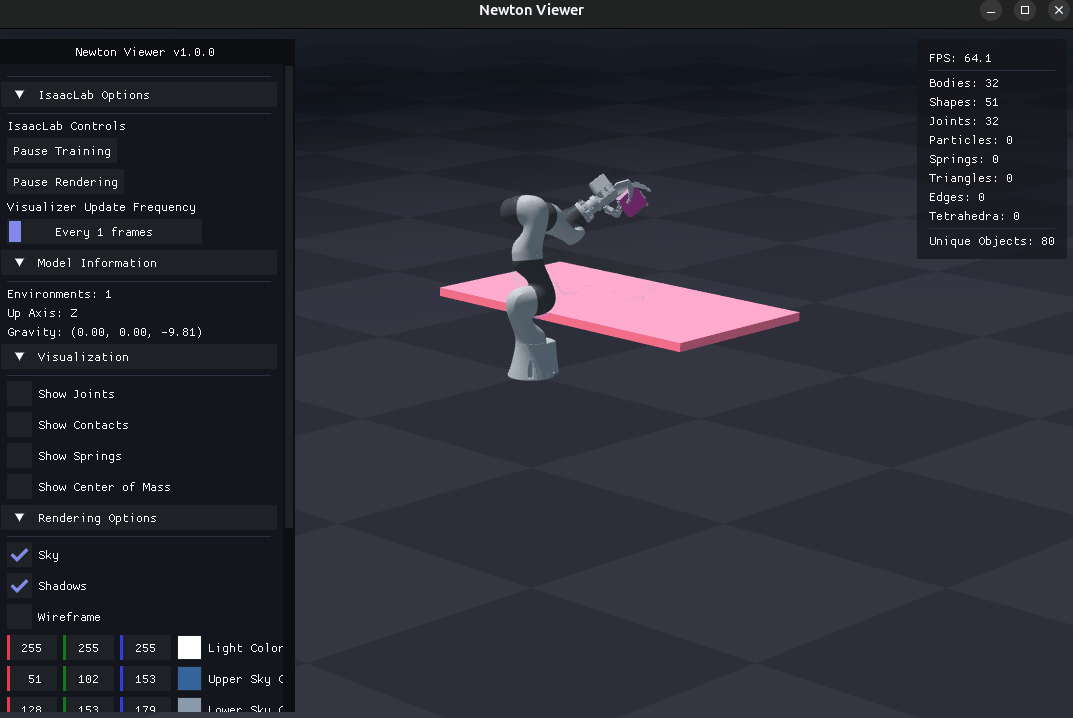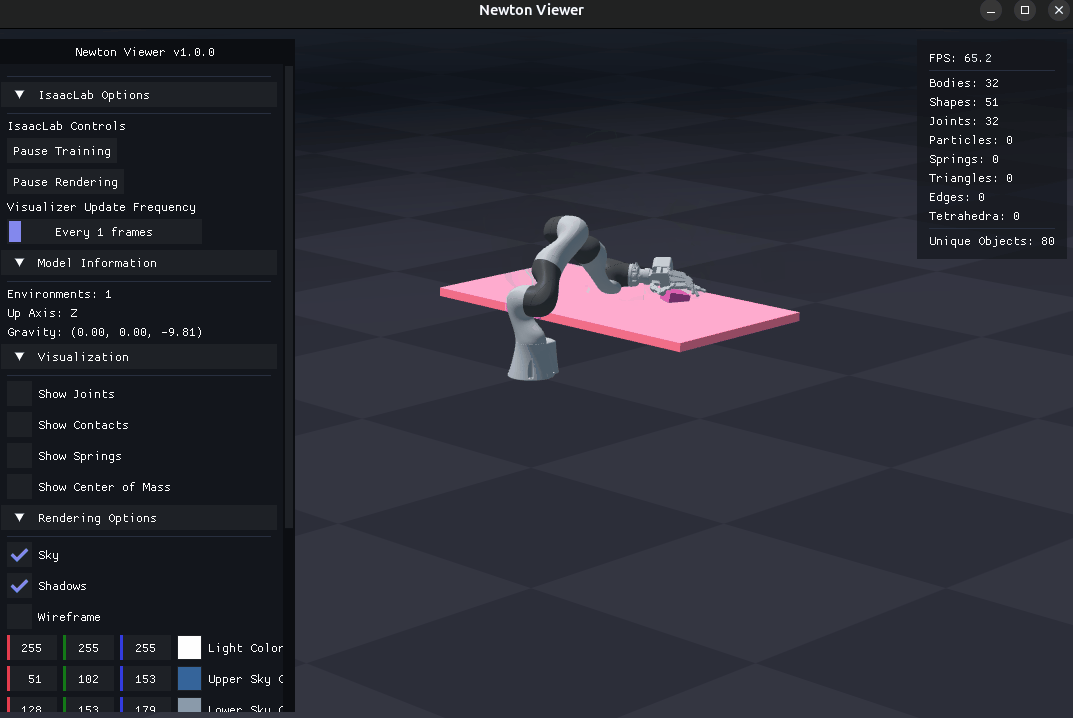
This example is an experimental showcase for the Isaac Lab 3.0 Newton physics backend, demonstrating dexterous object lifting with the Kuka Allegro hand. Training is performed in Isaac Lab and the resulting checkpoint is evaluated in Arena — both using Newton (MuJoCo-Warp solver) for physically accurate contact modelling during dexterous manipulation.
Important
Newton Physics — Experimental
The dexsuite_lift environment defaults to Newton physics. Newton can
also be selected explicitly for other Arena environments by passing
--presets newton. However, Newton support is experimental — only
this example has been verified to work with Newton under the current
simulation settings. Other
environments may require additional tuning of solver parameters and physics parameters
to run correctly using Newton physics.
Task Overview#
Task ID: dexsuite_lift
Task Description: The Kuka arm with an Allegro dexterous hand lifts a procedurally generated cuboid to a commanded target position using joint-space actions and contact-rich proprioceptive observations — including fingertip contact forces, hand-tip body states, object point cloud, and 5-step observation history.
Key Specifications:
Property |
Value |
|---|---|
Tags |
Dexterous manipulation, contact-rich |
Skills |
Reach, Grasp, Lift (multi-finger) |
Embodiment |
Kuka LBR iiwa + Allegro Hand (7 DOF arm + 16 DOF hand) |
Scene |
Procedural table (static background) with ground plane and lighting |
Objects |
Procedural lift cuboid ( |
Policy |
RSL-RL PPO ( |
Training Method |
Reinforcement Learning (on-policy PPO) — trained in Isaac Lab |
Physics Backend |
Newton (default) or PhysX ( |
Simulation Rate |
200 Hz physics, 50 Hz control (decimation = 4) |
Episode Length |
6 seconds |
Closed-loop |
Yes (50 Hz control) |
Command Space |
Target position [x, y, z], position-only, resampled every 2–3 s |
Note
Arena evaluation defaults to Newton for this environment. Pass
--presets physx to policy_runner.py to use PhysX instead. Isaac Lab
training selects Newton separately with physics=newton_mjwarp.
Workflow#
This tutorial covers training in Isaac Lab and evaluating the resulting checkpoint in Arena.
Prerequisites#
Start the Isaac Lab Arena docker container:
./docker/run_docker.sh
Workflow Steps#
Follow the steps below to complete the workflow: