



Transfer Policies Between PhysX and Newton#
Sim-to-sim transfer evaluates one policy checkpoint in a physics backend different from the one used for training. This guide covers both PhysX-trained policies deployed in Newton and Newton-trained policies deployed in PhysX.
The checkpoint maps ordered observations to actions; it does not include the physics engine. Transfer works when both backends expose the same policy inputs and outputs. Expect similar behavior, not identical trajectories. Successful transfer can be a first step toward sim-to-real deployment.
Task readiness and checkpoint compatibility#
The same registered task should describe the same Markov decision process (MDP) in both physics
engines. Selecting physics=isaacsim_physx or physics=newton_mjwarp resolves a backend alternative
through PresetCfg. Use that mechanism for intentional
backend-specific physics, asset, and control configuration. A physics preset should not silently
change policy-facing action, observation, reward, termination, command, or reset terms. If a
PresetCfg used by an MDP term does select different behavior, treat the resolved configurations
as different tasks: restore the original policy interface or retrain for the new configuration.
Before attempting transfer, prepare the assets using Prepare an Asset for Newton with MJWarp and ensure that the same task can be trained successfully in both engines. Then resolve each backend configuration and audit the policy interface. The following values must match exactly:
Policy interface |
Required equality |
|---|---|
Actions |
Term order, ordered joint or body names, width, target type, scale, offset, and clipping. |
Observations |
Group and term order, tensor width, history length, units, frames, clipping, and corruption behavior. |
Policy state |
Normalization statistics, recurrent-state shape and reset, commands, and privileged inputs used by the actor. |
Timing |
Physics |
Mechanism |
Ordered bodies and joints, active degrees of freedom, and mimic or equality coupling. |
Episode |
Reset and command distributions, reward and termination meanings, horizon, and success definition. |
Mimic-joint action nuance#
PhysX and Newton MJWarp preserve the leader and follower joint coordinates, but they do not create
the same drive graph. Newton imports the authored mimic relation as a mimic constraint, and
SolverMuJoCo lowers it to a MuJoCo mjEQ_JOINT equality constraint for MJWarp. The Franka
finger pair therefore has one active joint drive: panda_finger_joint1 is driven and the
constraint moves panda_finger_joint2. PhysX creates a native two-way articulation mimic
constraint, but the mimic follower still counts as a driveable joint. The constraint does not
disable a drive authored on that joint.
This distinction matters when an actuator expression such as panda_finger_joint.* assigns
nonzero stiffness and damping to both fingers. PhysX then has two active PD drives in addition to
the mimic coupling. When one logical gripper command is written to both finger targets, PhysX
applies drive effort through both joints, effectively applying the command twice relative to
MJWarp’s single driven finger. For the franka asset, we removed that discrepancy by driving only
the leader and explicitly making the follower passive:
"panda_hand": ImplicitActuatorCfg(
    joint_names_expr=["panda_finger_joint1"],
    # physical limits, gains, and armature
),
"panda_finger2_passive": ImplicitActuatorCfg(
    joint_names_expr=["panda_finger_joint2"],
    stiffness=0.0,
    damping=0.0,
    # retain the follower's limits and armature
),
Zero stiffness and damping are what disable the second PD drive. The follower remains in the articulation so the mimic constraint can move it.
Articulation joint and body ordering#
PhysX and MJWarp may order joints and bodies differently for branched robots. Set both
joint_ordering and body_ordering to one convention for training and for every playback;
physics= still selects the backend. Train in PhysX with physx and keep it on both PhysX and
Newton playback. A Newton-trained checkpoint already uses mjwarp order, so set mjwarp on the
PhysX playback. The task table below lists which tasks need the overrides and which do not.
See Joint and body ordering for the full ordering contract, accepted values, and troubleshooting.
A scrambled axis has a distinctive signature: a locomotion policy falls within a few dozen steps in every environment rather than degrading gracefully. Rule ordering out before attributing such a collapse to contacts, friction, or actuator response. Once the axes agree, the transferred policy should survive on a timescale comparable to its source baseline, and whatever gap remains is solver dynamics.
Transferring control behavior#
Match the nominal actuator response before tuning the policy:
distinguish the physical
actuator_velocity_limitfrom the solverjoint_velocity_limit;use per-joint effort, stiffness, damping, friction, and armature;
preserve
dt * decimationand action hold;keep targets away from hard joint stops;
monitor saturation and consecutive action sign changes.
Increased damping is often necessary to prevent bang-bang control. With too little damping, a position policy can alternate saturated commands and exploit one solver’s drive integration or limit response. Armature is equally important in MJWarp: it adds reflected inertia to the generalized mass matrix and prevents small contact or drive impulses from producing excessive joint or angular velocity. Retune damping after increasing armature because the effective natural frequency and damping ratio change. See Prepare an Asset for Newton with MJWarp for the actuator audit and physical sourcing guidance.
Introducing domain randomization#
Domain randomization is a useful technique for preventing policies from overfitting to a specific solver. Adding randomization to solver-relevant attributes, such as joint gains and friction, improves the policy’s ability to adapt to variations in solver behavior.
Family |
Transfer purpose |
Important nuance |
|---|---|---|
Robot and object friction |
Covers material and contact-model uncertainty. |
Current Newton event behavior uses one friction coefficient. PhysX static/dynamic values and buckets do not map one-to-one. |
Object mass and inertia |
Covers payload and geometry variation. |
Keep inertia positive and physically consistent. Decide explicitly whether changing mass recomputes inertia. |
Joint gains and friction |
Covers actuator identification and loss uncertainty. |
Accommodate variations in solver behavior even when the same attributes are used across engines. |
Joint armature |
Covers reflected-inertia uncertainty and MJWarp-sensitive acceleration. |
Use positive, physically supported ranges and randomize coupled mechanisms coherently. |
Gravity |
Eases lift learning and covers load variation. |
Progress to full nominal gravity and evaluate there. Zero gravity is not the deployment condition. |
Actuator response |
Covers gripper closing speed or motor response. |
Randomize the drive to accommodate differences in solver behavior. |
Reset pose and geometry |
Covers grasp and contact diversity. |
Re-run collision-valid reset checks for every geometry variant. |
Observation noise |
Reduces dependence on backend-specific state estimates. |
Match a plausible sensor and never change tensor shape or ordering. |
Domain randomization should span plausible modeling uncertainty, not arbitrarily wide values. If a distribution must become extreme for transfer to work, revisit the nominal model and the feature the policy is exploiting.
Use curriculum when the final distribution prevents early learning. Zero gravity, low observation noise, tighter reset ranges, or easier termination bounds can form the initial stage, but the curriculum must promote to the final deployment distribution. Keep a separate deterministic nominal evaluation so random draws do not obscure backend differences.
Validate the full matrix#
Evaluate every training/deployment combination:
Training backend |
Deployment backend |
Label and purpose |
|---|---|---|
PhysX |
PhysX |
PP: PhysX source baseline. |
PhysX |
Newton |
PN: PhysX-to-Newton transfer. |
Newton |
Newton |
NN: Newton source baseline. |
Newton |
PhysX |
NP: Newton-to-PhysX transfer. |
The exact entry point can vary by RL library. With the unified Isaac Lab entry point:
1. Train in PhysX:
uv run isaaclab train --rl_library rsl_rl --task TRAIN_TASK physics=isaacsim_physx \
    env.scene.robot.joint_ordering=physx env.scene.robot.body_ordering=physx
PP: reproduce source baseline in PhysX
uv run isaaclab play --rl_library rsl_rl --task PLAY_TASK \
    --checkpoint logs/rsl_rl/EXPERIMENT_DIRECTORY/RUN_DIRECTORY/model_ITERATION.pt physics=isaacsim_physx \
    env.scene.robot.joint_ordering=physx env.scene.robot.body_ordering=physx
PN: deploy PhysX checkpoint in Newton
uv run isaaclab play --rl_library rsl_rl --task PLAY_TASK \
    --checkpoint logs/rsl_rl/EXPERIMENT_DIRECTORY/RUN_DIRECTORY/model_ITERATION.pt physics=newton_mjwarp \
    env.scene.robot.joint_ordering=physx env.scene.robot.body_ordering=physx
2. Train in Newton:
uv run isaaclab train --rl_library rsl_rl --task TRAIN_TASK physics=newton_mjwarp
NN: reproduce source baseline in Newton
uv run isaaclab play --rl_library rsl_rl --task PLAY_TASK \
    --checkpoint logs/rsl_rl/EXPERIMENT_DIRECTORY/RUN_DIRECTORY/model_ITERATION.pt physics=newton_mjwarp
NP: deploy Newton checkpoint in PhysX
uv run isaaclab play --rl_library rsl_rl --task PLAY_TASK \
    --checkpoint logs/rsl_rl/EXPERIMENT_DIRECTORY/RUN_DIRECTORY/model_ITERATION.pt physics=isaacsim_physx \
    env.scene.robot.joint_ordering=mjwarp env.scene.robot.body_ordering=mjwarp
Drop the two ordering overrides when the task’s joint and body order already agrees across backends. See Articulation joint and body ordering.
A checkpoint trained in PhysX without physx set uses Isaac Sim PhysX’s own order, which can
differ from physx. To replay it, record joint_names and body_names from a PhysX run
without an ordering, using the same asset and Isaac Sim version, and set them as explicit
joint_ordering and body_ordering lists. The lists must match the target backend’s names
exactly, so assets whose backends name joints or bodies differently, such as Humanoid-AMP’s
multi-axis joints, or that repeat a body name on Newton, cannot be replayed this way.
Validated transfer examples#
The following tasks have been validated for cross-backend transfer. Substitute TRAIN_TASK /
PLAY_TASK with the task ID and EXPERIMENT_DIRECTORY with the directory below into the
generic commands above.
Task |
Experiment directory |
Notes |
|---|---|---|
|
|
No ordering override needed; joint and body order is identical in both backends. The
|
|
|
Branched topology: set the ordering overrides shown in the generic commands above. |
|
|
Branched topology: same ordering overrides as G1. |
Transfer demonstrations#
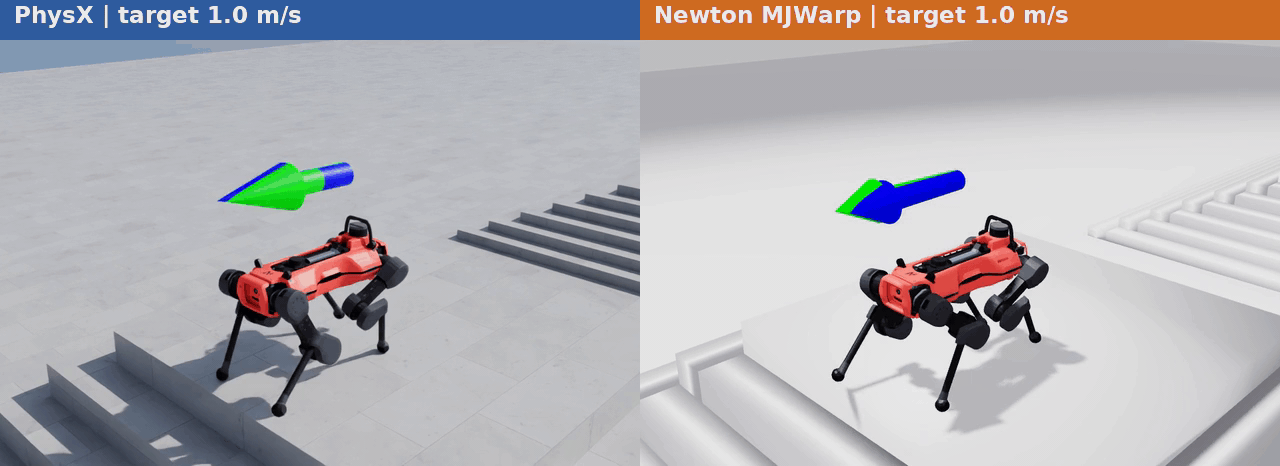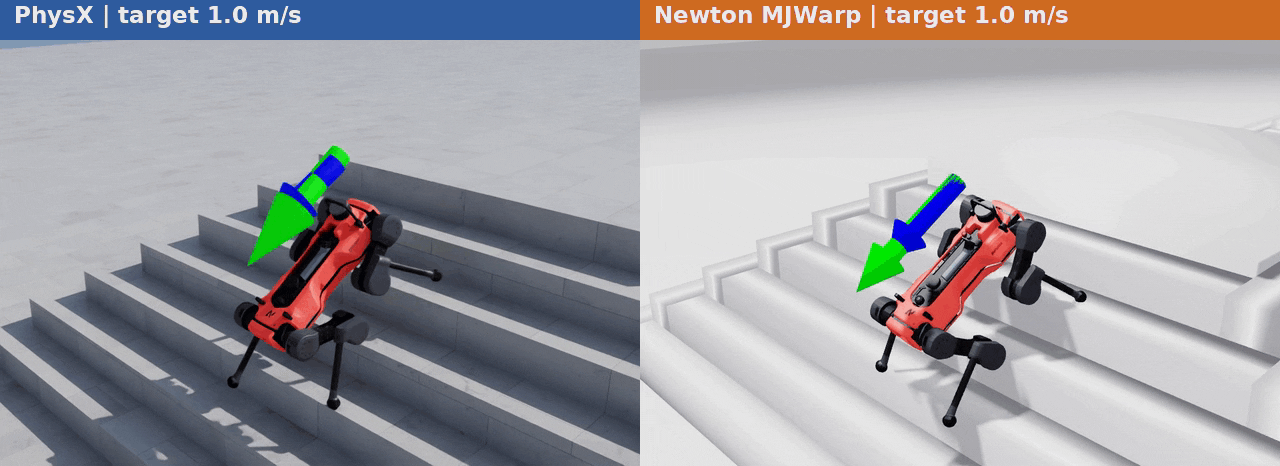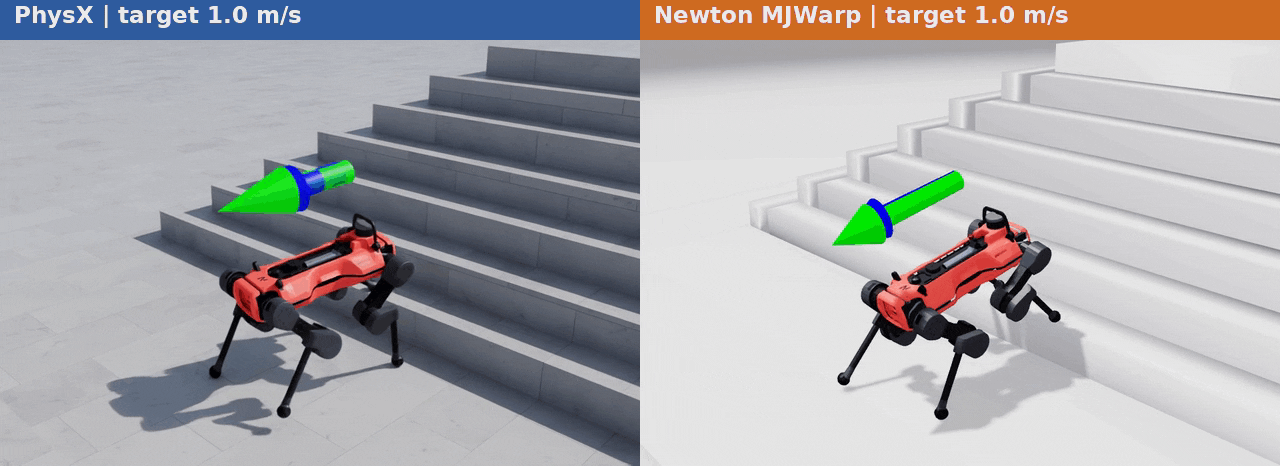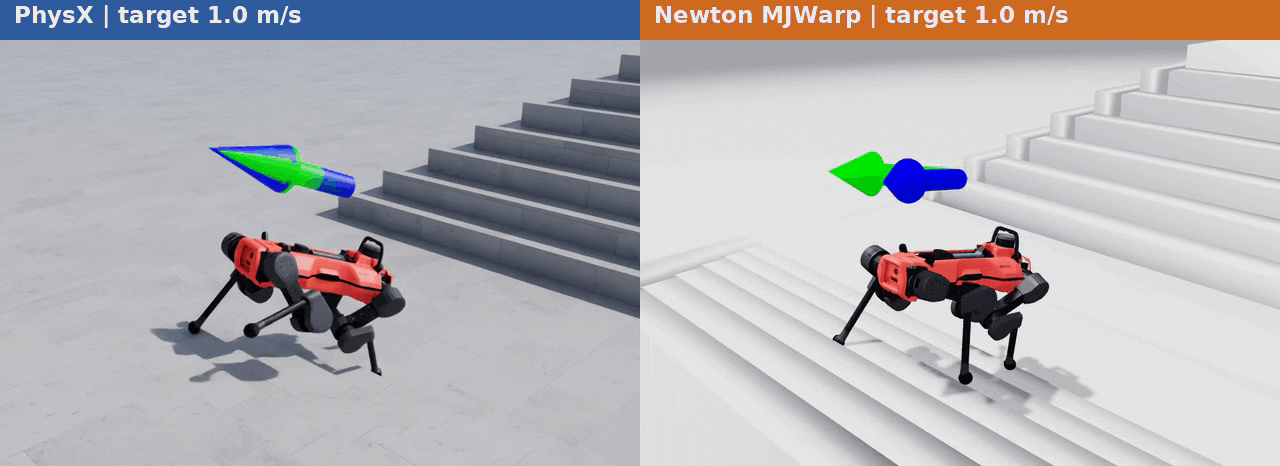
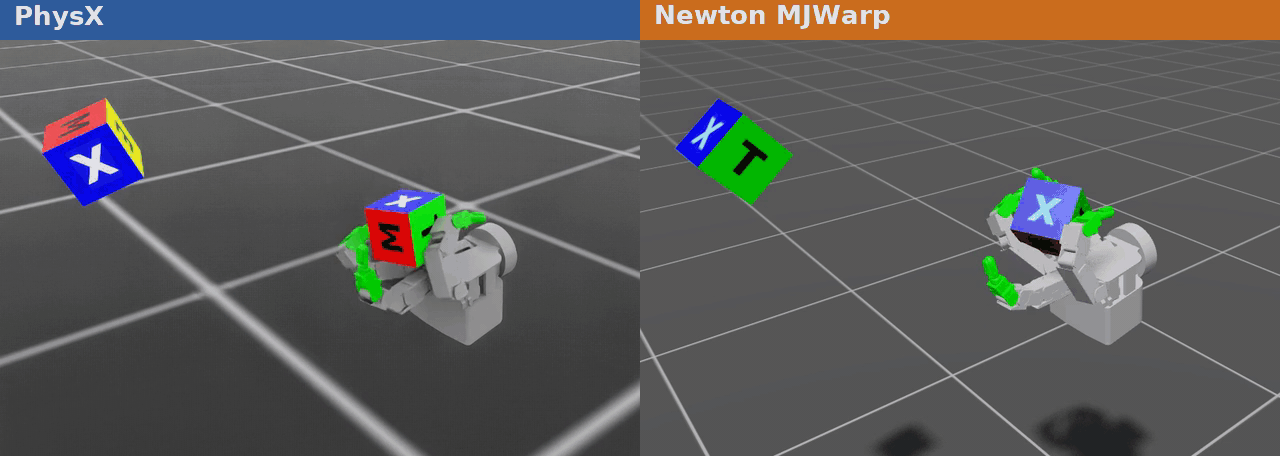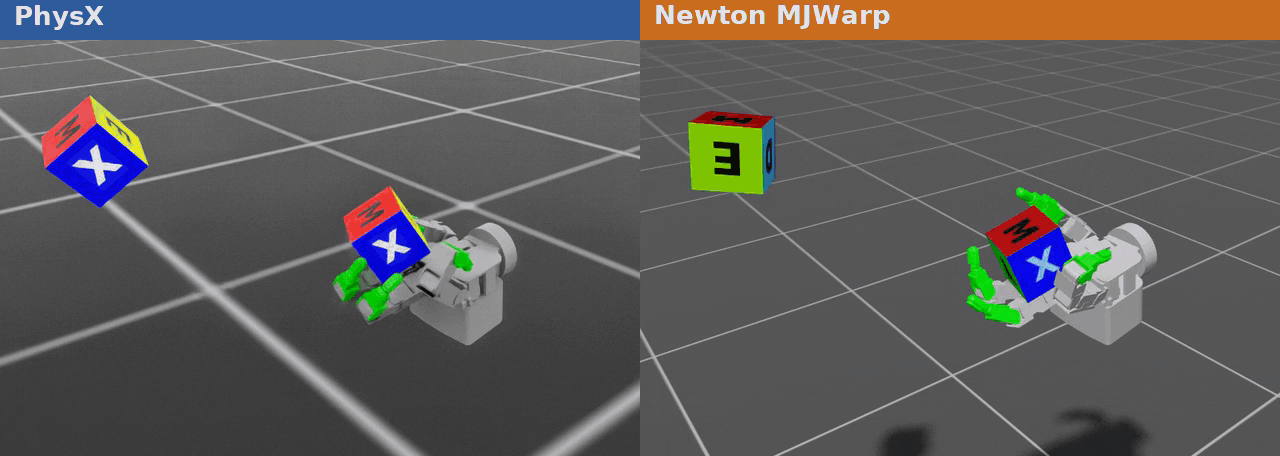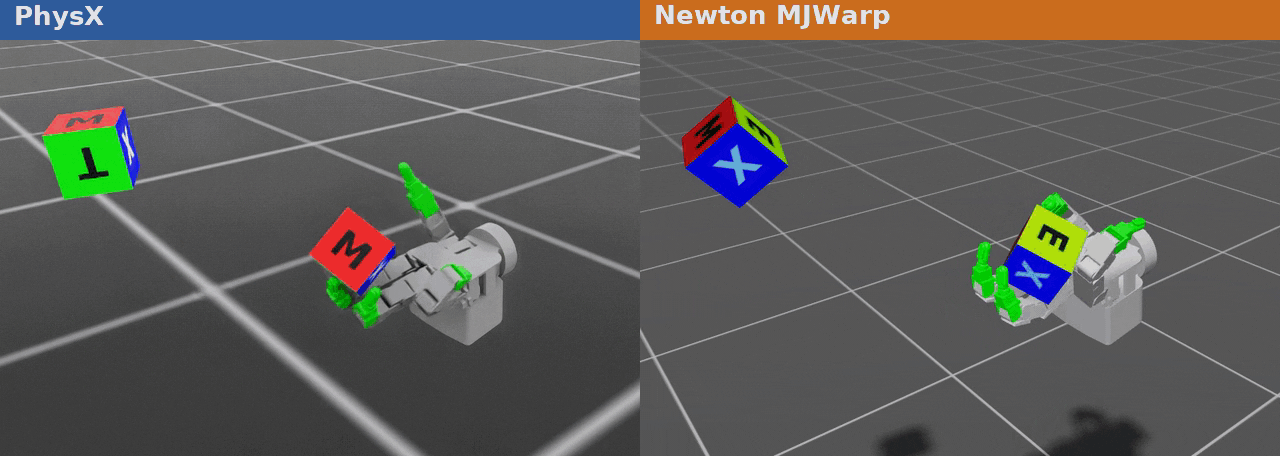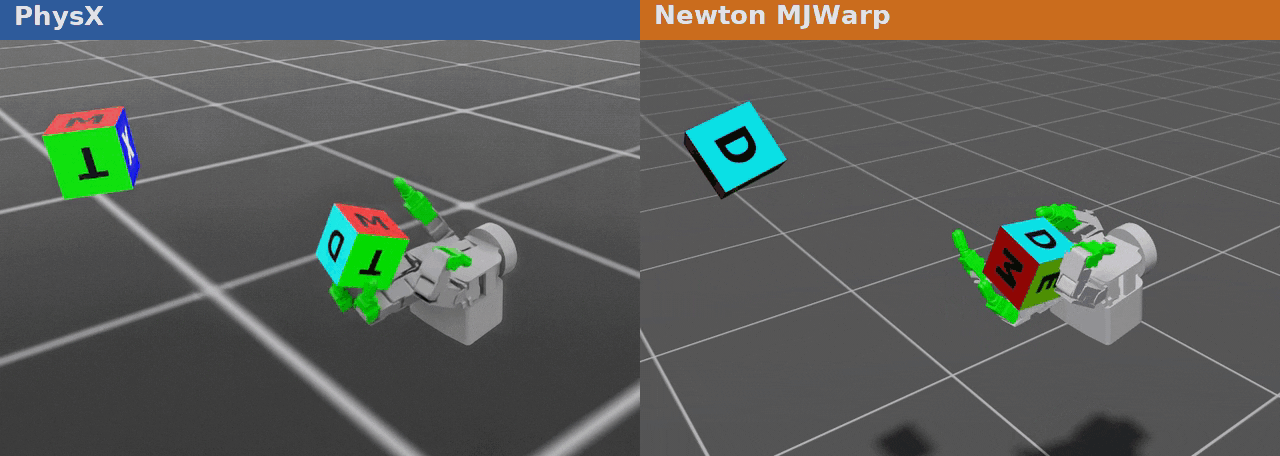
These videos demonstrate PhysX-trained policies running in Newton MJWarp without retraining. They do not represent full PP/PN/NN/NP validation. The backends are shown side by side.
ANYmal-D rough-terrain locomotion (Isaac-Velocity-Rough-AnymalD)
Allegro hand cube reorientation (Isaac-Reorient-Cube-Allegro, PhysX-to-Newton direction only)
Tip
For Allegro transfer, contact stiffness (ke), contact damping (kd), contact friction,
joint damping, and joint friction are the key parameters to tune. Increasing solver substeps
to 4–16 significantly improves contact stability during in-hand manipulation.
Joint and body ordering#
PhysX and MJWarp may order an articulation’s joints and bodies differently. Set
joint_ordering and body_ordering to keep names mapped to the same tensor elements
across backends. This section explains the supported conventions, conversion costs, and direct
backend-view access. For backend selection and capabilities, see Physics Backends.
Why articulation orders differ#
Three facts explain why a checkpoint can need an ordering convention even when both backends load the same USD asset:
USD names identify physical joints and bodies, but they do not impose one universal tensor-axis order across solvers.
PhysX and MJWarp construct native articulation views with different topology traversal and internal representation choices.
Isaac Lab resolves the requested names once during articulation initialization, then exposes the selected public order through its high-level API.
The backend selection described in Backend architecture controls which native view is created. The ordering selection controls how the high-level API presents that view.
The two PhysX backends also differ from each other. Both list links breadth-first, but Isaac Sim PhysX visits the child links of each link in authored joint-prim order, while OVPhysX visits them by joint type, then joint prim path. They agree whenever sibling joints are authored in that order.
Public and backend order#
Set joint_ordering and body_ordering on
ArticulationCfg. Each field accepts one of:
None– backend-native order and the zero-conversion default (see below)."physx"– OVPhysX articulation-view order. Other backends, Isaac Sim PhysX included, resolve it from the asset with Newton’s USD parser and map their own order to it. Resolution raises when it cannot reproduce that order: Newton cannot import the asset, the backends name its joints or bodies differently, or a floating articulation rooted on a container prim has tied graph centers, nested bodies or loop-closing joints. KeepNoneor set explicit name lists for those articulations."mjwarp"– Newton or MJWarp articulation-view order."robot_schema"– the order authored on the asset’sisaac:physics:robotJoints(joints) orisaac:physics:robotLinks(bodies) relationships.an explicit, complete name permutation – a
listortuplenaming every joint or body exactly once.
See joint_ordering for the
authoritative list of accepted values.
For Python configs, prefer
apply_articulation_ordering_preset() to set both fields
to the same convention in a single call, which keeps joint and body order
consistent:
from isaaclab.assets import apply_articulation_ordering_preset

robot_cfg = apply_articulation_ordering_preset(robot_cfg, "mjwarp")
Warning
When overriding from the CLI or Hydra, set both joint_ordering and
body_ordering. Setting only joint_ordering silently leaves bodies in
backend order, which mismatches a checkpoint whose body vectors follow the
source convention.
Incoming joint wrenches read through
body_joint_wrench also follow public body order.
See Joint Wrench Sensor for enabling wrench data and backend root-body coverage.
Once initialized, the articulation and its
ArticulationNameMap objects establish this contract:
Surface |
Ordering contract |
|---|---|
|
Public order |
|
Public order |
Articulation command and property writers |
Public input order |
|
Backend order |
|
Backend order |
|
Bridge between public and backend order |
None is the zero-conversion default. Public names follow the active
backend, no ordering map is installed, no reorder staging is allocated, and no
reorder kernel is launched. An explicit convention or name sequence that
resolves to backend order is normalized to None at initialization after a
one-time name resolution, so it reaches the exact same zero-conversion state:
a non-None ordering map always denotes an actual permutation.
Tip
After configuring an ordering, confirm the resolved public axis by comparing
joint_names with
backend_joint_names (and body_names
with backend_body_names). Cross-backend conventions are resolved by
emulation, so spot-check the result against the order your checkpoint expects.
High-level MDP terms#
Standard MDP terms that consume high-level articulation data use public
indices. This includes terms that resolve joint or body selections by name and
then index public-order ArticulationData properties
or call high-level articulation writers.
Material randomization crosses the backend boundary explicitly: it converts
selected public body IDs to backend body IDs before deriving the corresponding
backend shape ranges. Custom or backend-specific MDP code that accesses
root_view bypasses these high-level conversions and must convert its own
indices and tensors.
Conversion cost#
Convention resolution and map construction are one-time initialization work. For a nonidentity map, affected reads and writes can require persistent staging memory plus gather/scatter kernel launches. Identity maps avoid those ongoing conversion paths.
On the Newton backend, a nonidentity ordering additionally records a fixed per-step reorder of the core state buffers – joint positions and velocities, body poses and velocities – inside the stepped and CUDA-graph-captured region. This publishes backend-order state into the public-order buffers every step, so a small baseline per-step cost exists independent of how often properties are accessed.
The runtime and memory cost scales with environment count, joint or body count, and how often affected properties and writers are accessed. Measure the specific task and access pattern; there is no hardware-independent steps-per-second number or fixed percentage overhead.
Direct backend-view access#
Warning
Arrays returned by the raw solver view (root_view) are always in
backend solver order, regardless of the configured joint_ordering or
body_ordering. Indices from joint_names, body_names,
find_joints, or find_bodies are in public order and must not be
used to index root_view arrays directly. Use the asset’s data
buffers and write APIs, which already operate in public order, or
translate indices through the asset’s joint_ordering/body_ordering
maps first.
Prefer the high-level articulation API when possible; its data and writer
contracts already use public order. Direct root_view access uses backend
order even when joint_names or body_names uses another convention.
When a small set of indices needs to cross into a view array, translate them
with map_joint_ids_to_backend() or
map_body_ids_to_backend() instead of
indexing the ordering maps by hand; both return the input unchanged under
identity ordering.
Torch conversion#
To gather a backend-order joint tensor into public order, enumerate public
output columns and use user_to_backend_indices to select the matching
backend source columns:
ordering = robot.joint_ordering
if ordering is None:
    joint_pos_public = joint_pos_backend
else:
    joint_pos_public = joint_pos_backend[:, list(ordering.user_to_backend_indices)]
For the opposite direction, enumerate backend output columns and use
backend_to_user_indices to select the matching public source columns:
ordering = robot.joint_ordering
if ordering is None:
    joint_target_backend = joint_target_public
else:
    joint_target_backend = joint_target_public[:, list(ordering.backend_to_user_indices)]
Use robot.body_ordering in the same way for body-indexed axes. Keep the
None guard because it avoids an unnecessary gather and means no map object
exists.
Warp conversion#
The elementwise reorder kernels in
isaaclab.assets.articulation.ordering_kernels translate raw-view arrays
between backend and public order. For example,
reorder_2d_backend_to_user gathers one (environment, joint) array into
public order:
import warp as wp

from isaaclab.assets.articulation.ordering_kernels import reorder_2d_backend_to_user


ordering = robot.joint_ordering
if ordering is None:
    joint_pos_public = joint_pos_backend
else:
    joint_pos_public = wp.empty(
        (robot.num_instances, robot.num_joints),
        dtype=wp.float32,
        device=robot.device,
    )
    wp.launch(
        reorder_2d_backend_to_user,
        dim=(robot.num_instances, robot.num_joints),
        inputs=[joint_pos_backend, ordering.user_to_backend],
        outputs=[joint_pos_public],
        device=robot.device,
    )
The caller owns output allocation, launch dimensions, data type, and every
non-articulation axis. A public-to-backend gather uses
ordering.backend_to_user. Treat both device maps as read-only.
The reorder_2d and reorder_3d kernels, in both the *_backend_to_user
and *_user_to_backend directions, form this public elementwise family. All
other kernels in isaaclab.assets.articulation.ordering_kernels are internal
and may change without deprecation.
Joint maps cover named joints, not floating-base generalized coordinates.
When converting raw Jacobians or mass matrices, preserve the leading
robot.num_base_dofs coordinates and offset mapped joint indices by that
count. Apply the joint permutation to both generalized-coordinate axes of a
mass matrix and leave all other axes unchanged.
The public floating-base Jacobian body rows use the full public body order; to
convert a raw backend Jacobian, gather with the full body map. Fixed-base raw
backend Jacobians omit the fixed root, so do not apply the full body map
directly. Omit public/root body index 0 and convert each remaining mapped
backend body ID to a Jacobian row by subtracting 1. The fixed-root-first
invariant makes this well-defined. See
body_link_jacobian_w for the
authoritative body-axis convention. High-level articulation data performs
these conversions automatically.
What ordering does not solve#
Ordering compatibility keeps names attached to the same vector elements; it does not make simulated trajectories match. Policy behavior can still diverge because of:
contact generation and resolution
friction
restitution
integration method
timestep and substeps
solver convergence
Use Solver Differences to diagnose and tune these differences rather than treating them as ordering failures.
Verification and troubleshooting#
When a transferred policy behaves unexpectedly, check these items in order:
Compare public
joint_namesandbody_nameswithbackend_joint_namesandbackend_body_names.Confirm both joint and body source conventions when the policy or task uses both kinds of vector.
Verify observation and action dimensions against the training run.
Audit custom code for direct
root_viewaccess.Compare source and target values by physical name rather than by raw column.
When name-to-vector semantics are stable but motion still diverges, classify the problem as a solver-dynamics issue and continue with Solver Differences.