
Environments#
Build a command and browse the core and contributed tasks available in Isaac Lab.
Command Builder#
This environment does not support RL training or playback. The command runs it with the zero-action agent instead.
This combination of physics, renderer, and preset can't launch. Choose a different option.
Task Preview#
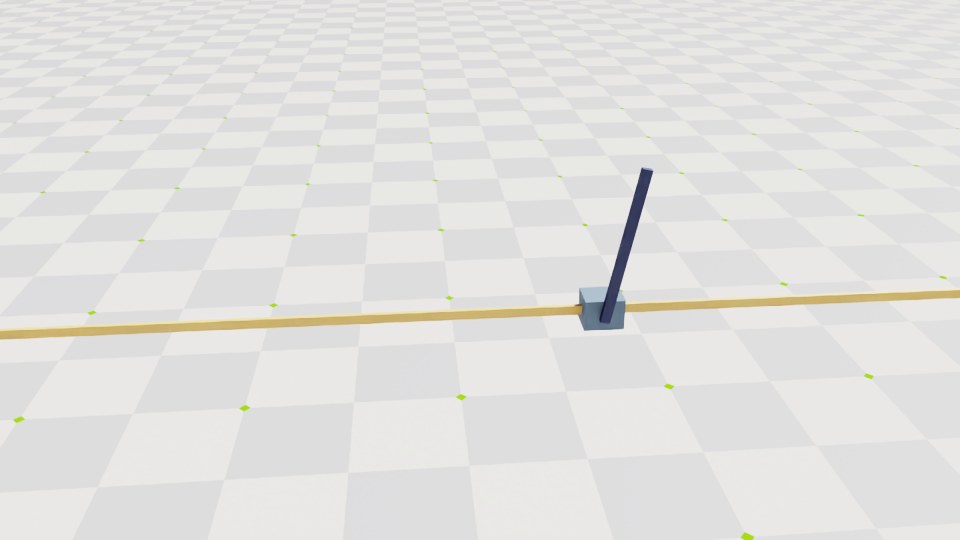
Selected task
Isaac-Cartpole
- Mode
- Train
- RL Library
- rsl_rl
- Physics
- newton_mjwarp
- Renderer
- Default
- Preset
- Default
- VRAM
- Not available
Try Manipulation in Your Browser#
UR10 reach and Franka lift use pretrained policies. Cube stacking uses a scripted controller. Each scene also offers Manual end-effector control.
Explore manipulationOpen gallery
Interactive demos load when this section is visible.
Benchmarks#
Benchmark data is not available yet
Benchmark data could not be loaded.
Available Tasks#
No tasks match this search.