


Interactive Demos#
Explore physics and trained policies in your browser—no installation required. Select a demo below to get started.
Tuning
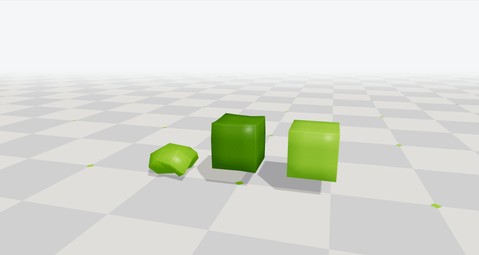
Compare three deformable cubes. Adjust shear, volume stiffness, damping, and gravity, then repeat the same drop.
Tuning
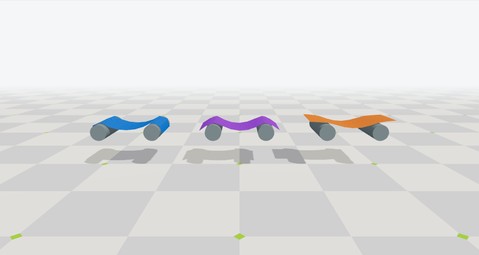
Compare cloth sheets draping over rollers. Change the middle sheet’s bending stiffness and gravity.
Tuning
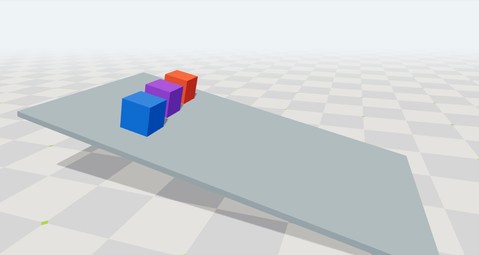
Change a box’s friction on an incline and compare its sliding motion with two fixed material references.
Tuning
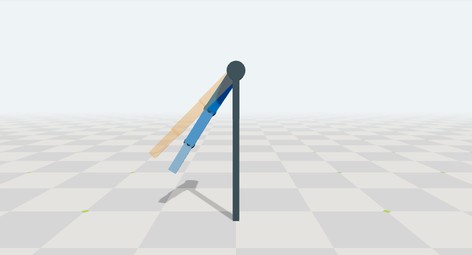
Tune a suspended three-joint arm with step and sine commands. Compare target and measured angles on the live tracking plot.
Tuning
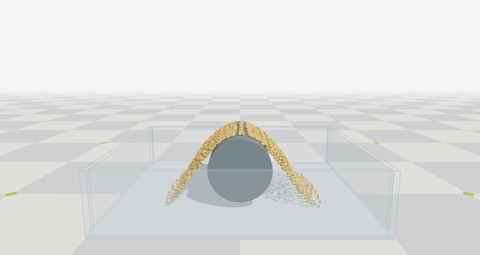
Drop 2,744 fine particles onto a cylinder inside a catch tub. Try sand, snow, clay, and water references, or tune individual parameters.
Tuning
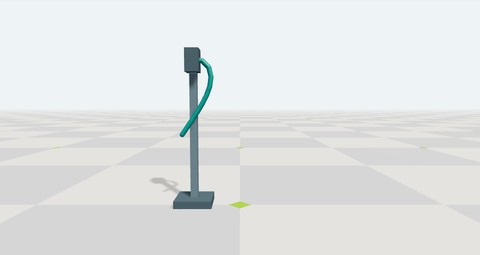
Bend a clamped 0.45 m, ten-segment cable. Adjust bending stiffness and downward tip load, then reset to compare the response.
Tuning
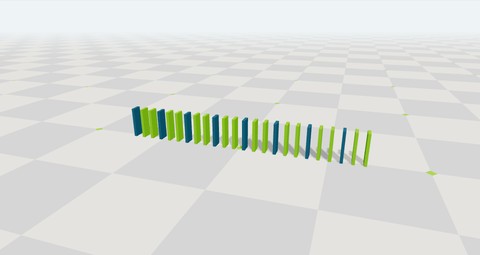
Topple 24 slabs with a short push. Change friction and replay the cascade using Newton XPBD and the Isaac Lab checker ground.
Policy
Push a pretrained balancing policy with up to 300 N in either direction. Release the slider to watch it recover.
Policy
Command forward, sideways, and turning motion with travel and yaw pads using the published WBC-AGILE policy.
Policy
Drive an ANYmal-D with travel and yaw pads using a published Isaac Lab Newton checkpoint.
Policy
Walk in a bounded warehouse. Drag sticks to their edges to lock commands; pull back or press Escape to stop. Drag the robot for a 2 N push.
Policy
Move the target position and watch a pretrained joint-position policy reach for it.
Policy
Watch a pretrained policy lift a cube from a pregrasp reset. Adjust its target position, pause, or replay the episode.
Policy
Play, pause, and reset a pretrained drawer-opening policy. Orbit the camera to inspect the grasp and drawer motion.
Policy
Lift a flexible beam with a pretrained VBD policy. Change its target height or stiffness, or pull the beam to test recovery.
Policy
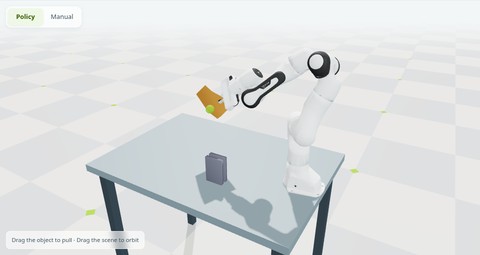
Watch a pretrained VBD policy grasp a cloth sheet through contact. Adjust bending stiffness or target height, or pull the cloth.
Scripted
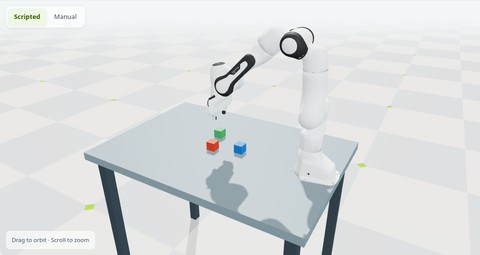
Stack two 50 mm cubes with a scripted IK controller and simulated gripper contacts, or take over the arm in Manual mode.
About these demos#
Each demo runs a Newton simulation locally on your CPU through WebAssembly, with camera controls, pause, and reset. Simplified scenes and adapted policy playback can behave differently from native tasks. Use the full Isaac Lab environments for training and measured comparisons.
Simulation bundles, policy checkpoints, exporters, and third-party license notices are distributed through the interactive-demos release. See the original implementation.