Deformable Pick and Place#
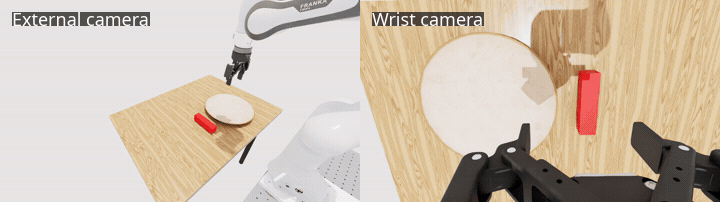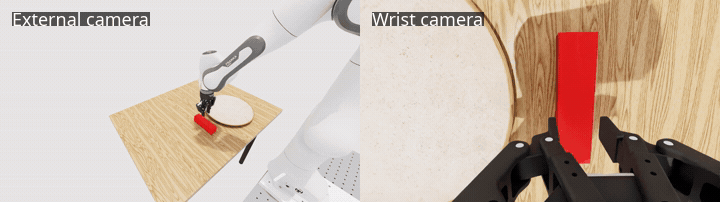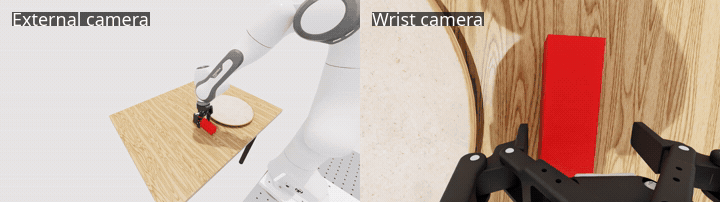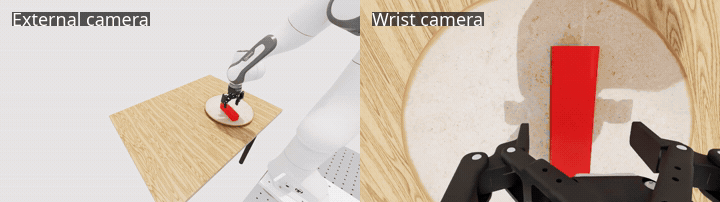
Pick up a deformable cube with the DROID robot and place it on a plate. The same task can run with either the Newton or PhysX deformable-body backend. This walkthrough covers previewing the environment, teleoperating it, and evaluating an OpenPI policy.
Task Overview#
Property |
Value |
|---|---|
Task ID |
|
Embodiment |
DROID; absolute joint-position control for OpenPI and differential inverse kinematics for teleoperation |
Scene |
Maple table with a deformable cube and a plate |
Task |
Pick up the cube, place it on the plate, and let it settle |
Physics |
Newton by default; select the backend-specific deformable asset for PhysX. See Newton’s VBD solver tuning guide for deformable simulation parameters. |
Prerequisites#
Complete the Arena installation and start your Arena
runtime. Run these commands from the repository root in the activated native environment or
inside the Base Docker container (/workspaces/isaaclab_arena).
Preview the Environment#
Use a zero-action policy to inspect either backend:
python isaaclab_arena/evaluation/policy_runner.py \
  --policy_type zero_action \
  --num_steps 1000 \
  --num_envs 1 \
  --viz kit \
  droid_deformable_pick_and_place \
  --pick_object deformable_cube_newton
python isaaclab_arena/evaluation/policy_runner.py \
  --policy_type zero_action \
  --num_steps 1000 \
  --num_envs 1 \
  --viz kit \
  droid_deformable_pick_and_place \
  --pick_object deformable_cube_physx
The preview exits after 1,000 steps. Increase --num_steps for a longer preview, or press
Ctrl+C in the terminal to stop it.
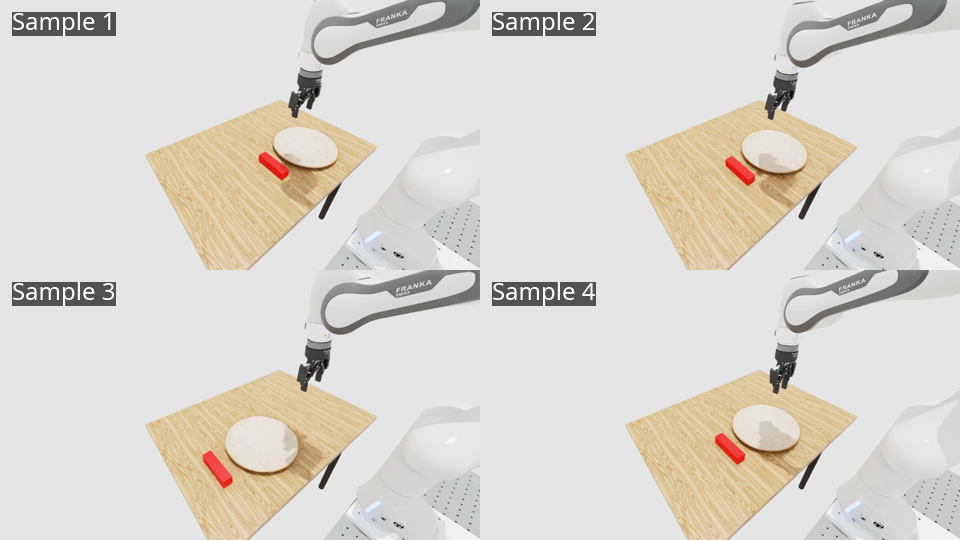
You should see the DROID robot with a deformable cube and a round plate on the maple table. The placement relations are the same for both physics backends, with the initial poses sampled as shown below.
Teleoperate the Task#
The Isaac Lab teleoperation script can control the task through Arena’s interop callback. Choose the tab for your input device, then run the command for the simulation backend.
See SpaceMouse Setup (Optional) for the required host permissions and Docker setup.
Newton
python submodules/IsaacLab/scripts/environments/teleoperation/teleop_se3_agent.py \
  --task droid_deformable_pick_and_place \
  --external_callback isaaclab_arena.environments.isaaclab_interop.environment_registration_callback \
  --teleop_device keyboard \
  --viz kit \
  --pick_object deformable_cube_newton \
  --embodiment droid_differential_ik
PhysX
python submodules/IsaacLab/scripts/environments/teleoperation/teleop_se3_agent.py \
  --task droid_deformable_pick_and_place \
  --external_callback isaaclab_arena.environments.isaaclab_interop.environment_registration_callback \
  --teleop_device keyboard \
  --viz kit \
  --pick_object deformable_cube_physx \
  --embodiment droid_differential_ik
Controls
Action |
Input |
|---|---|
Move along the X axis |
|
Move along the Y axis |
|
Move along the Z axis |
|
Rotate about the X axis |
|
Rotate about the Y axis |
|
Rotate about the Z axis |
|
Open or close the gripper |
|
Reset the current attempt |
|
Newton
python submodules/IsaacLab/scripts/environments/teleoperation/teleop_se3_agent.py \
  --task droid_deformable_pick_and_place \
  --external_callback isaaclab_arena.environments.isaaclab_interop.environment_registration_callback \
  --teleop_device spacemouse \
  --viz kit \
  --pick_object deformable_cube_newton \
  --embodiment droid_differential_ik
PhysX
python submodules/IsaacLab/scripts/environments/teleoperation/teleop_se3_agent.py \
  --task droid_deformable_pick_and_place \
  --external_callback isaaclab_arena.environments.isaaclab_interop.environment_registration_callback \
  --teleop_device spacemouse \
  --viz kit \
  --pick_object deformable_cube_physx \
  --embodiment droid_differential_ik
Controls
Action |
Input |
|---|---|
Move the gripper |
Move the cap laterally or vertically |
Change the gripper orientation |
Rotate the cap |
Open or close the gripper |
Press the left button |
Reset the current attempt |
Press the right button |
Note
The cube in this example uses MeshCuboidCfg, which initially authors only a triangle
surface mesh. A volume deformable also needs a tetrahedral simulation mesh, so Isaac Lab
calls fTetWild during scene creation when it cannot find an existing UsdGeom.TetMesh.
This on-the-fly conversion is nondeterministic between process launches and may produce
different node counts or connectivity. Demonstration datasets include the initial nodal
state, which can be restored only into the same topology. If deterministic topology is
required, including for recording and replay, pre-generate a USD containing a
UsdGeom.TetMesh and use that asset instead.
Evaluate with OpenPI#
Start the local OpenPI server in a separate terminal:
./isaaclab_arena_openpi/docker/run_openpi_server.sh
Then evaluate four parallel environments for 16 completed episodes:
python isaaclab_arena/evaluation/policy_runner.py \
  --policy_type isaaclab_arena_openpi.policy.pi0_remote_policy.Pi0RemotePolicy \
  --num_episodes 16 \
  --num_envs 4 \
  --viz kit \
  --enable_cameras \
  droid_deformable_pick_and_place \
  --pick_object deformable_cube_newton
A local 16-episode OpenPI pi05 validation run succeeded in 9 episodes (56.25%).
This small stochastic run validates the workflow.
[Rank 0/1] Metrics: {'num_episodes': 16, 'success_rate': 0.5625, 'object_moved_rate': 1.0}
python isaaclab_arena/evaluation/policy_runner.py \
  --policy_type isaaclab_arena_openpi.policy.pi0_remote_policy.Pi0RemotePolicy \
  --num_episodes 16 \
  --num_envs 4 \
  --viz kit \
  --enable_cameras \
  droid_deformable_pick_and_place \
  --pick_object deformable_cube_physx
A local 16-episode OpenPI pi05 validation run succeeded in 15 episodes (93.75%).
This small stochastic run validates the workflow.
[Rank 0/1] Metrics: {'num_episodes': 16, 'success_rate': 0.9375, 'object_moved_rate': 1.0}
The following rollout shows one successful Newton episode from an external camera and the robot wrist camera: