

Step 3: Generate the Dataset#
SoftMimicGen generates new demonstrations by randomizing the rope’s starting configuration, selecting a source demonstration by nodal registration cost, and warping the source end-effector trajectory to the current rope shape. It then executes the adapted trajectory and evaluates task success.
The commands below use the pre-annotated source datasets that ship with the repository. Use the source dataset that matches your physics backend:
dataset_franka_rope_newton_annotated.hdf5
If you ran Steps 1–2, set --input_file to
./datasets/dataset_franka_rope_newton_annotated.hdf5 instead.
dataset_franka_rope_physx_annotated.hdf5
If you ran Steps 1–2, set --input_file to
./datasets/dataset_franka_rope_physx_annotated.hdf5 instead.
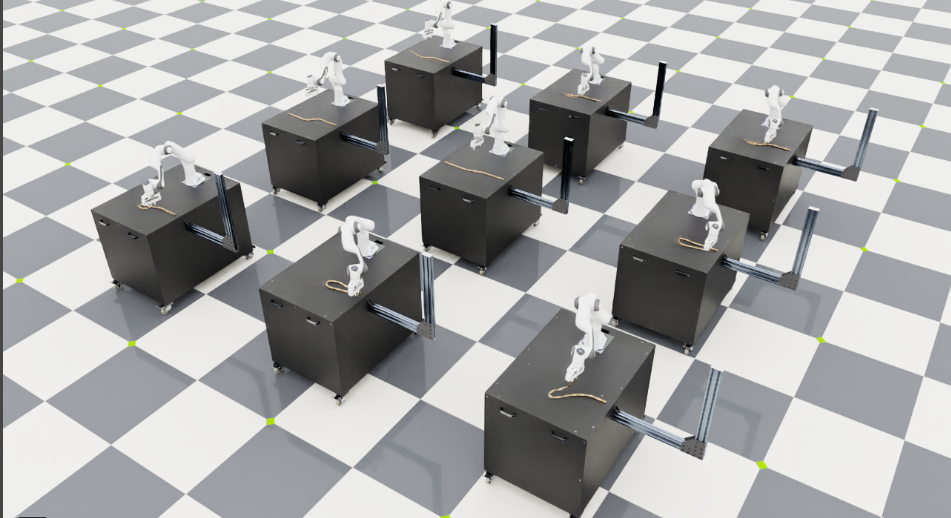
Parallel environments generating data with SoftMimicGen.#
Small-Scale Generation#
Start with two parallel environments in a Kit window to inspect the generated motions:
python scripts/generate_dataset.py \
    --env_name Isaac-Rope-Franka-Arena-IK-Rel-v0 \
    --presets newton \
    --viz kit \
    --device cuda \
    --enable_cameras \
    --num_envs 2 \
    --alg softmimicgen \
    --generation_num_trials 5 \
    --task_descriptor autodata_examples/tasks/franka_rope_softmimicgen.yaml \
    --embodiment autodata_examples/embodiments/franka_ik_rel.yaml \
    --input_file ./datasets/annotated_datasets/dataset_franka_rope_newton_annotated.hdf5 \
    --output_file ./datasets/generated_dataset_softmimicgen_franka_rope_newton_small.hdf5
python scripts/generate_dataset.py \
    --env_name Isaac-Rope-Franka-Arena-IK-Rel-v0 \
    --presets physx \
    --viz kit \
    --device cuda \
    --enable_cameras \
    --num_envs 2 \
    --alg softmimicgen \
    --generation_num_trials 5 \
    --task_descriptor autodata_examples/tasks/franka_rope_softmimicgen.yaml \
    --embodiment autodata_examples/embodiments/franka_ik_rel.yaml \
    --input_file ./datasets/annotated_datasets/dataset_franka_rope_physx_annotated.hdf5 \
    --output_file ./datasets/generated_dataset_softmimicgen_franka_rope_physx_small.hdf5
Failed attempts are normal. The task descriptor sets guarantee_success: true
so generation retries until it reaches the target of 5 successful
demonstrations and exports only successes. The console reports progress and success rate.
Full-Scale Generation#
After checking the small run, generate 100 successful demonstrations with 10 parallel
environments and run without the Kit window. Adjust --num_envs according to GPU memory
and observed throughput. Deformable simulation and camera recording can be expensive.
python scripts/generate_dataset.py \
    --env_name Isaac-Rope-Franka-Arena-IK-Rel-v0 \
    --presets newton \
    --viz none \
    --device cuda \
    --enable_cameras \
    --num_envs 10 \
    --alg softmimicgen \
    --generation_num_trials 100 \
    --task_descriptor autodata_examples/tasks/franka_rope_softmimicgen.yaml \
    --embodiment autodata_examples/embodiments/franka_ik_rel.yaml \
    --input_file ./datasets/annotated_datasets/dataset_franka_rope_newton_annotated.hdf5 \
    --output_file ./datasets/generated_dataset_softmimicgen_franka_rope_newton.hdf5
python scripts/generate_dataset.py \
    --env_name Isaac-Rope-Franka-Arena-IK-Rel-v0 \
    --presets physx \
    --viz none \
    --device cuda \
    --enable_cameras \
    --num_envs 10 \
    --alg softmimicgen \
    --generation_num_trials 100 \
    --task_descriptor autodata_examples/tasks/franka_rope_softmimicgen.yaml \
    --embodiment autodata_examples/embodiments/franka_ik_rel.yaml \
    --input_file ./datasets/annotated_datasets/dataset_franka_rope_physx_annotated.hdf5 \
    --output_file ./datasets/generated_dataset_softmimicgen_franka_rope_physx.hdf5
To generate state-only datasets, omit --enable_cameras. --viz none alone does not
disable image recording.
Key Parameters#
Parameter |
Description |
|---|---|
|
Physics backend: |
|
Use |
|
Generation target. With this descriptor’s |
|
Number of parallel simulation environments. |
|
Render and record the fixed-view and wrist RGB observations. |
|
|
Continue to Step 4: Validate the Generated Dataset.