Ctrl+K
isaaclab_arena - Home isaaclab_arena - Home

isaaclab_arena

main 0.3.0 0.3.0-prerelease 0.2.1 0.2.0 0.1.1 0.1.0
  • GitHub
isaaclab_arena - Home isaaclab_arena - Home

isaaclab_arena

  • GitHub

Table of Contents

Isaac Lab-Arena

  • Overview
  • Why Isaac Lab-Arena

Set Up

  • Installation

Getting Started

  • First Arena Environment
  • First Arena Experiment
  • Exploring Environment Variations
  • Running a Real Policy
    • OpenPI
    • GR00T

Arena in Your Repo

  • Arena in Your Repository
    • Installing IsaacLab-Arena in Your Repository
    • Defining Environments in Your Repository
    • Your Own Tasks and Embodiments

Example Workflows

  • Example Environments
    • RoboLab Task Catalog
    • Kitchen Benchmark Catalog
    • Python Environment Catalog
  • Evaluation
    • Run an Evaluation
    • Sensitivity Analysis
    • Multi-Node Evaluation
  • Agentic Environment Generation
    • Pick and Place atomic task with homogeneous objects
      • Run Agentic Environment Generation
      • Edit the Environment Graph Spec
      • Use the Generated Environment
    • Pick and Place atomic task with heterogeneous objects
      • Run Agentic Environment Generation
      • Edit the Environment Graph Spec
      • Use the Generated Environment
    • Pick and Place composite task with SimReady assets
      • Run Agentic Environment Generation
      • Edit the Environment Graph Spec
      • Use the Generated Environment
    • Pick and Place on a Kitchen Countertop
      • Run Agentic Environment Generation
      • Edit the Environment Graph Spec
      • Use the Generated Environment
    • Open a Kitchen Fridge Door
      • Run Agentic Environment Generation
      • Edit the Environment Graph Spec
      • Use the Generated Environment
  • Imitation Learning
    • G1 Loco-Manipulation Box Pick and Place Task
      • Environment Setup and Validation
      • Teleoperation Data Collection
      • Data Generation
      • Policy Post-Training
      • Closed-Loop Policy Inference and Evaluation
    • GR1 Open Microwave Door Task
      • Environment Setup and Validation
      • Teleoperation Data Collection
      • Data Generation
      • Policy Post-training
      • Closed-Loop Policy Inference and Evaluation
    • GR1 Sequential Pick & Place and Close Door Task
      • Environment Setup and Validation
      • Teleoperation Data Collection
      • Data Generation
      • Policy Post-training
      • Closed-Loop Policy Inference and Evaluation
  • Reinforcement Learning
    • Franka Lift Object Task
      • Environment Setup and Validation
      • Policy Training
      • Closed-Loop Policy Inference and Evaluation
    • Dexsuite Kuka Allegro Lift Task (Newton)
      • Environment Setup and Validation
      • Policy Training (Isaac Lab)
      • Evaluation in Arena

Concepts

  • Environment
    • Environment Definition
    • Environment Builder
  • Agentic Environment Generation
    • System Overview
    • Inference Model and Spec Quality
    • GUI Runner
    • CLI Runner
  • Scene
    • Assets
    • Rigid Object Sets
    • Affordances
  • Task
    • Composite and Sequential Tasks
    • Predicates and Subtask Progress Tracking
    • RL Tasks
    • Metrics
  • Embodiment
    • Teleop Devices
  • Object and Robot Placement
    • Relations and Strategies
    • Collision Handling
    • Placement Solver
    • Placement Validation
    • Pooled Placement
    • Homogeneous and Heterogeneous Object Placement
  • Policy
  • Arena Experiments
  • Variations
    • Variations
  • Sensitivity Analysis

Advanced

  • Omniverse Authentication
  • Assets Management
  • Jupyter Notebooks

References

  • Performance and scaling
  • Release Notes
  • Citing Isaac Lab-Arena

Gallery

  • Gallery

Development Team Internal

  • Development Team Internal
    • DreamZero
  • Gallery

Gallery#

Swappable assets#

Run-time swapping of building blocks, including target objects and backgrounds, enables parallel evaluation across many variations of a task without code changes.

Relational object placement#

Define layouts with semantic spatial relations rather than hand-coded poses. Arena solves and validates candidate placements against object geometry, collisions, and task constraints.

Parallel policy evaluation#

Evaluate a policy across parallel environments, with aggregated metrics for high-level summaries and per-episode records for detailed analysis.

Agentic environment generation#
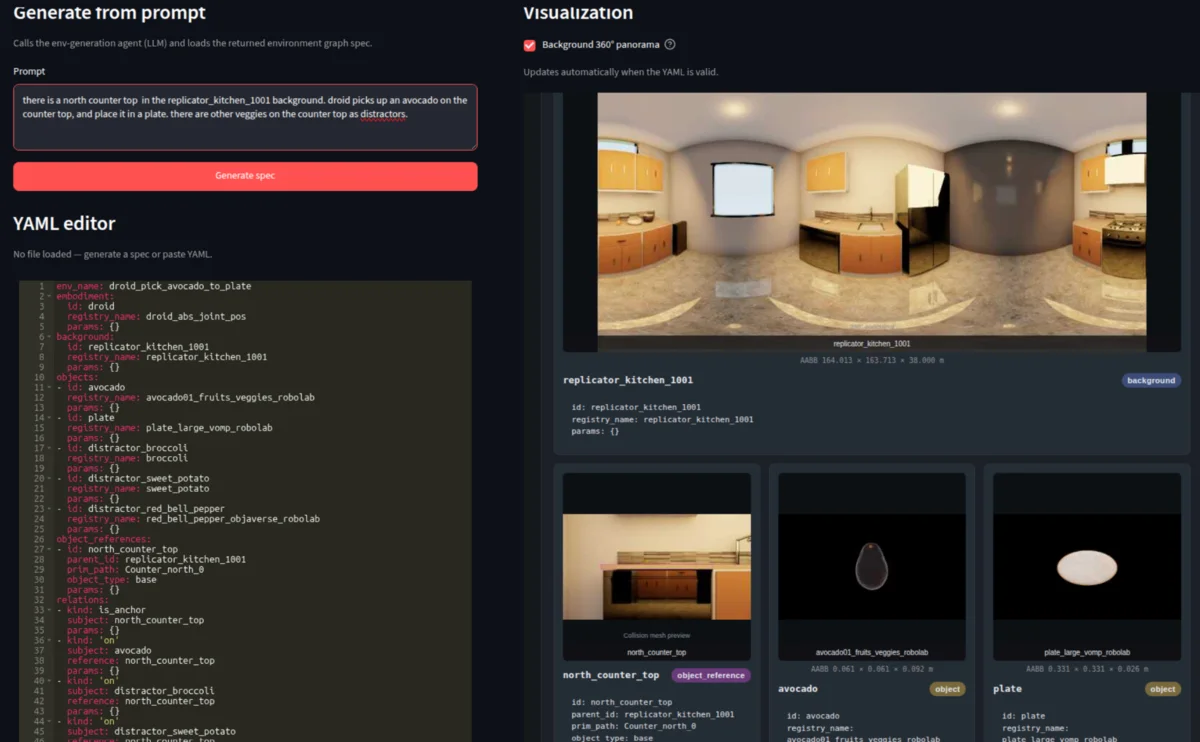
Generated Arena environment specification and scene preview

Turn a natural-language task request into a runnable Arena environment. Edit the environment specification and interactively review randomized layouts in the GUI.

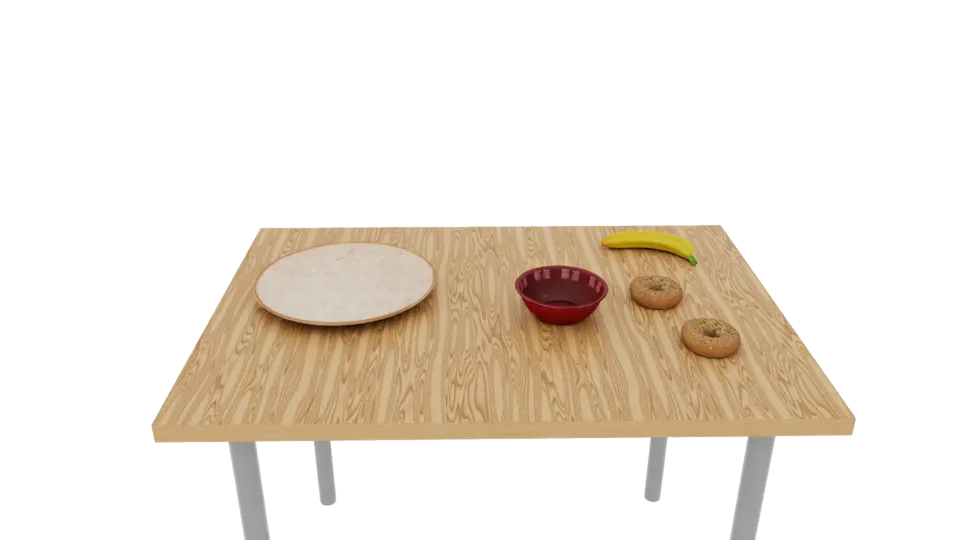
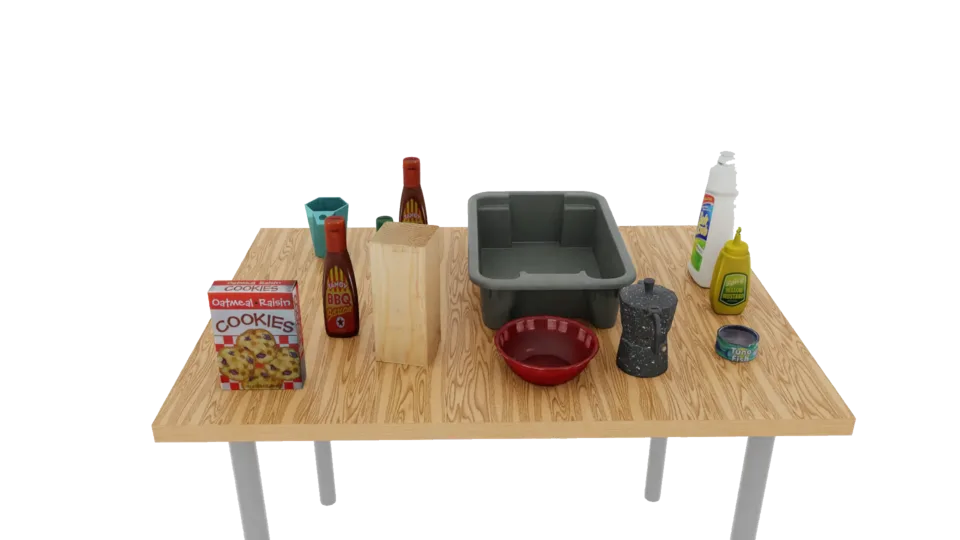
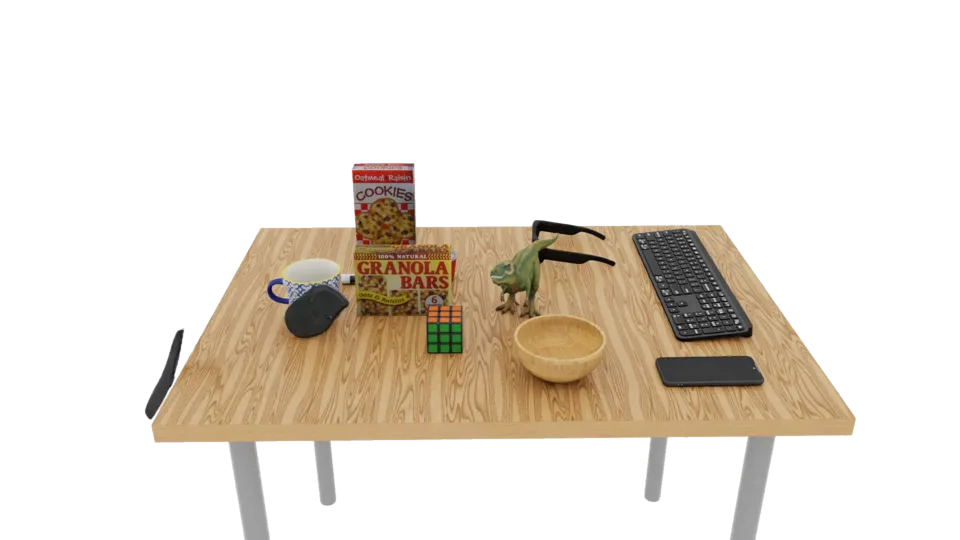
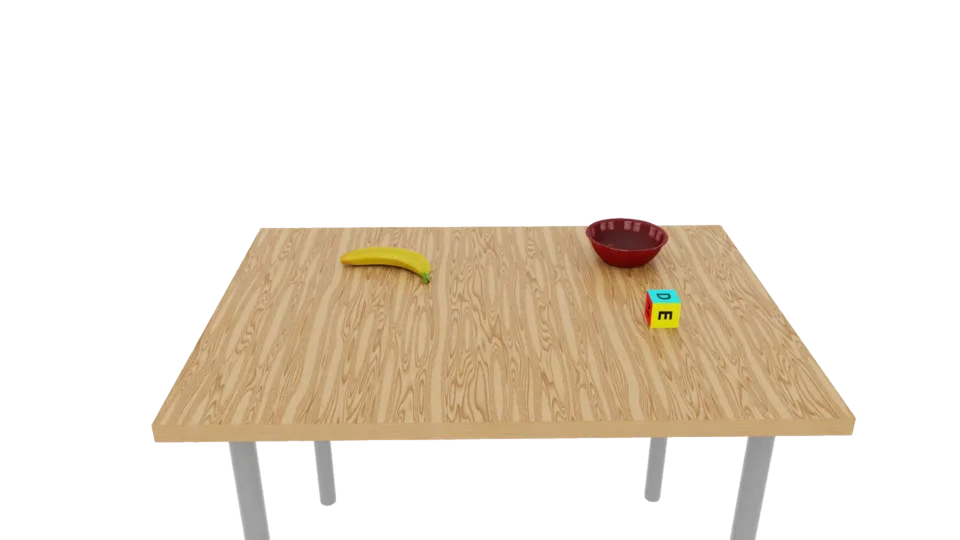
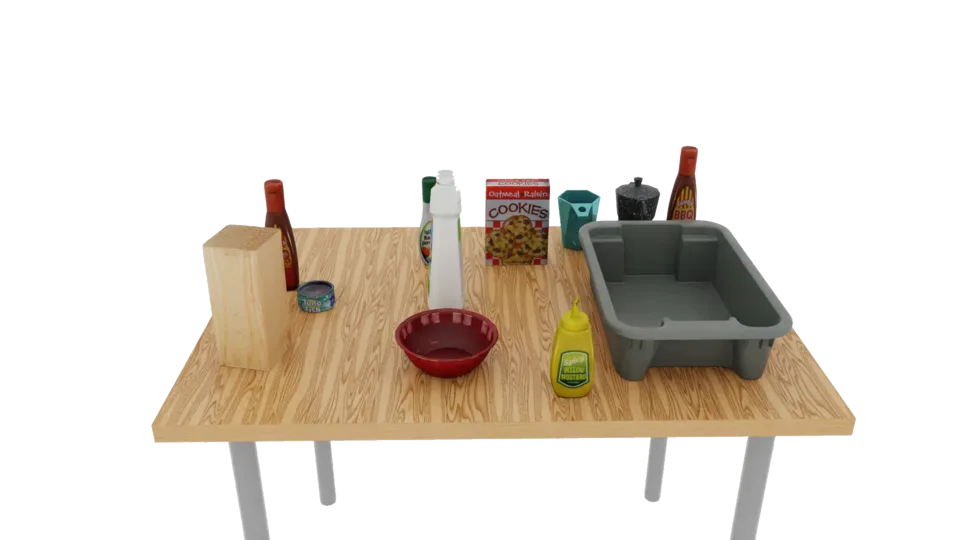
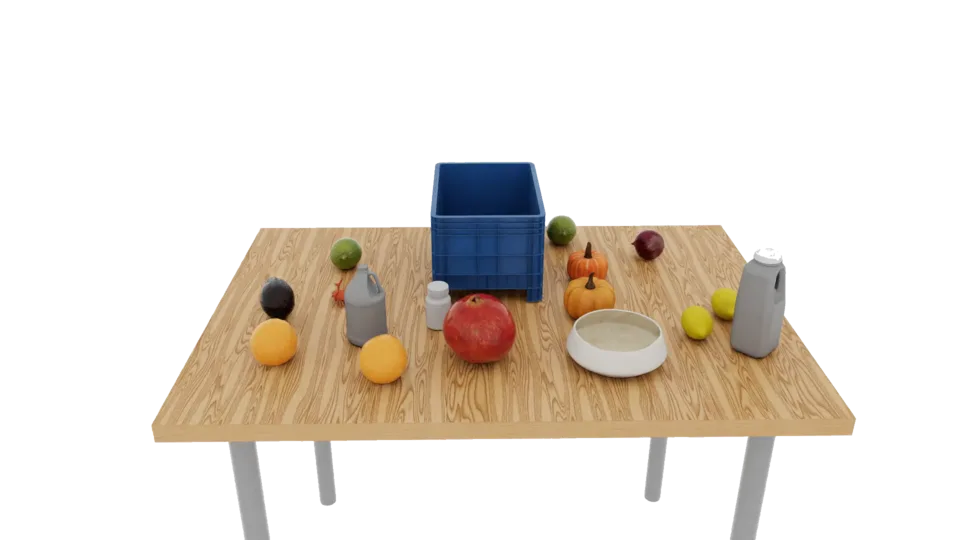
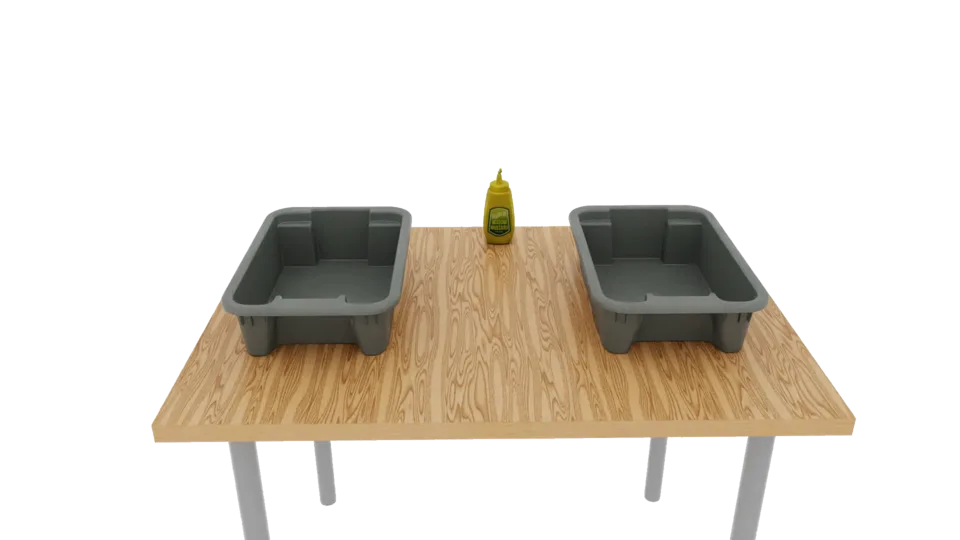
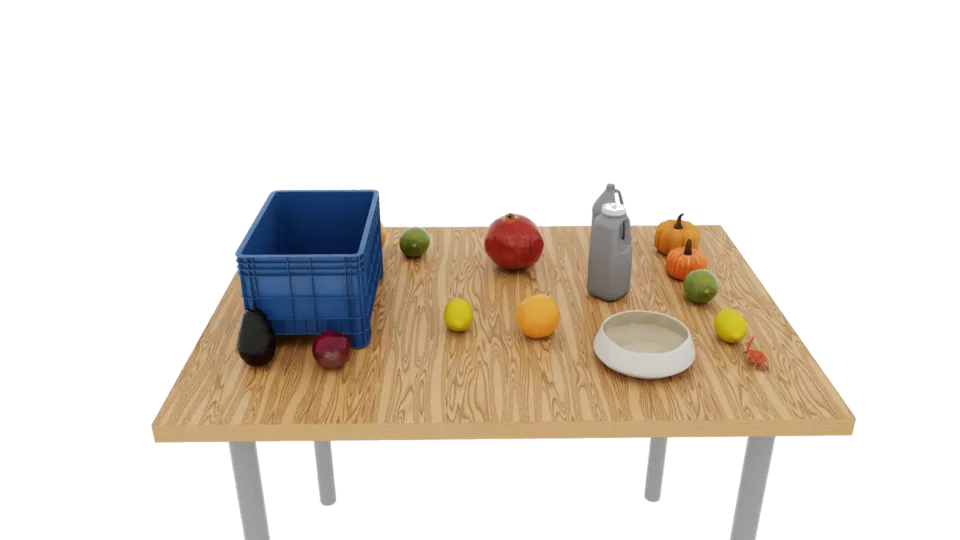
Built-in evaluation environments#
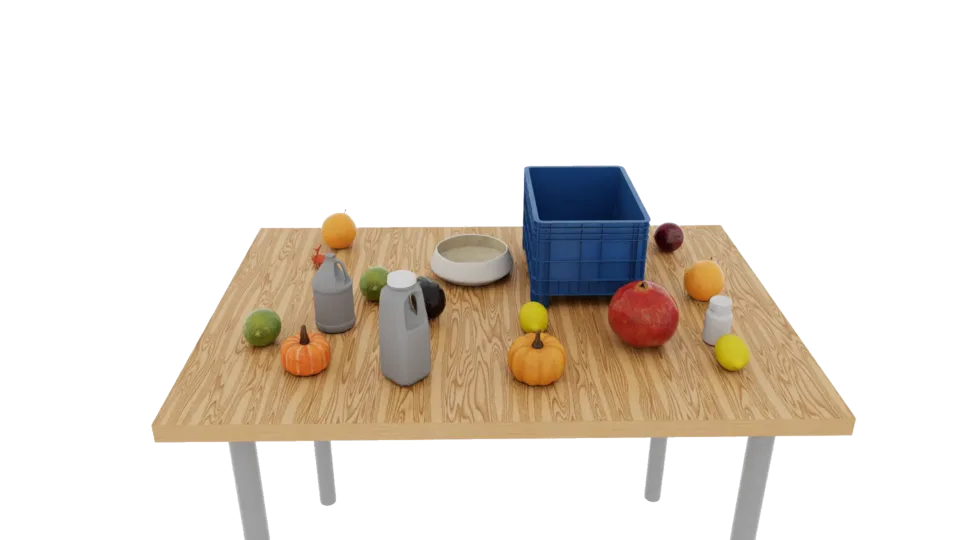
Big pumpkin in bin evaluation environment Bagels on plate evaluation environment Canned food in bin evaluation environment Mouse on keyboard evaluation environment Rubik's cube and banana evaluation environment Barbecue sauce in bin evaluation environment Small pumpkin in bin evaluation environment Mustard in left bin evaluation environment Pumpkin evaluation environment with surrounding clutter

Run policies against Arena’s built-in registered environments.

Environment variations#

Sample controlled build-time and run-time variations, including HDR backgrounds, light properties, camera intrinsics and extrinsics, and object mass.

Multi-node evaluation#
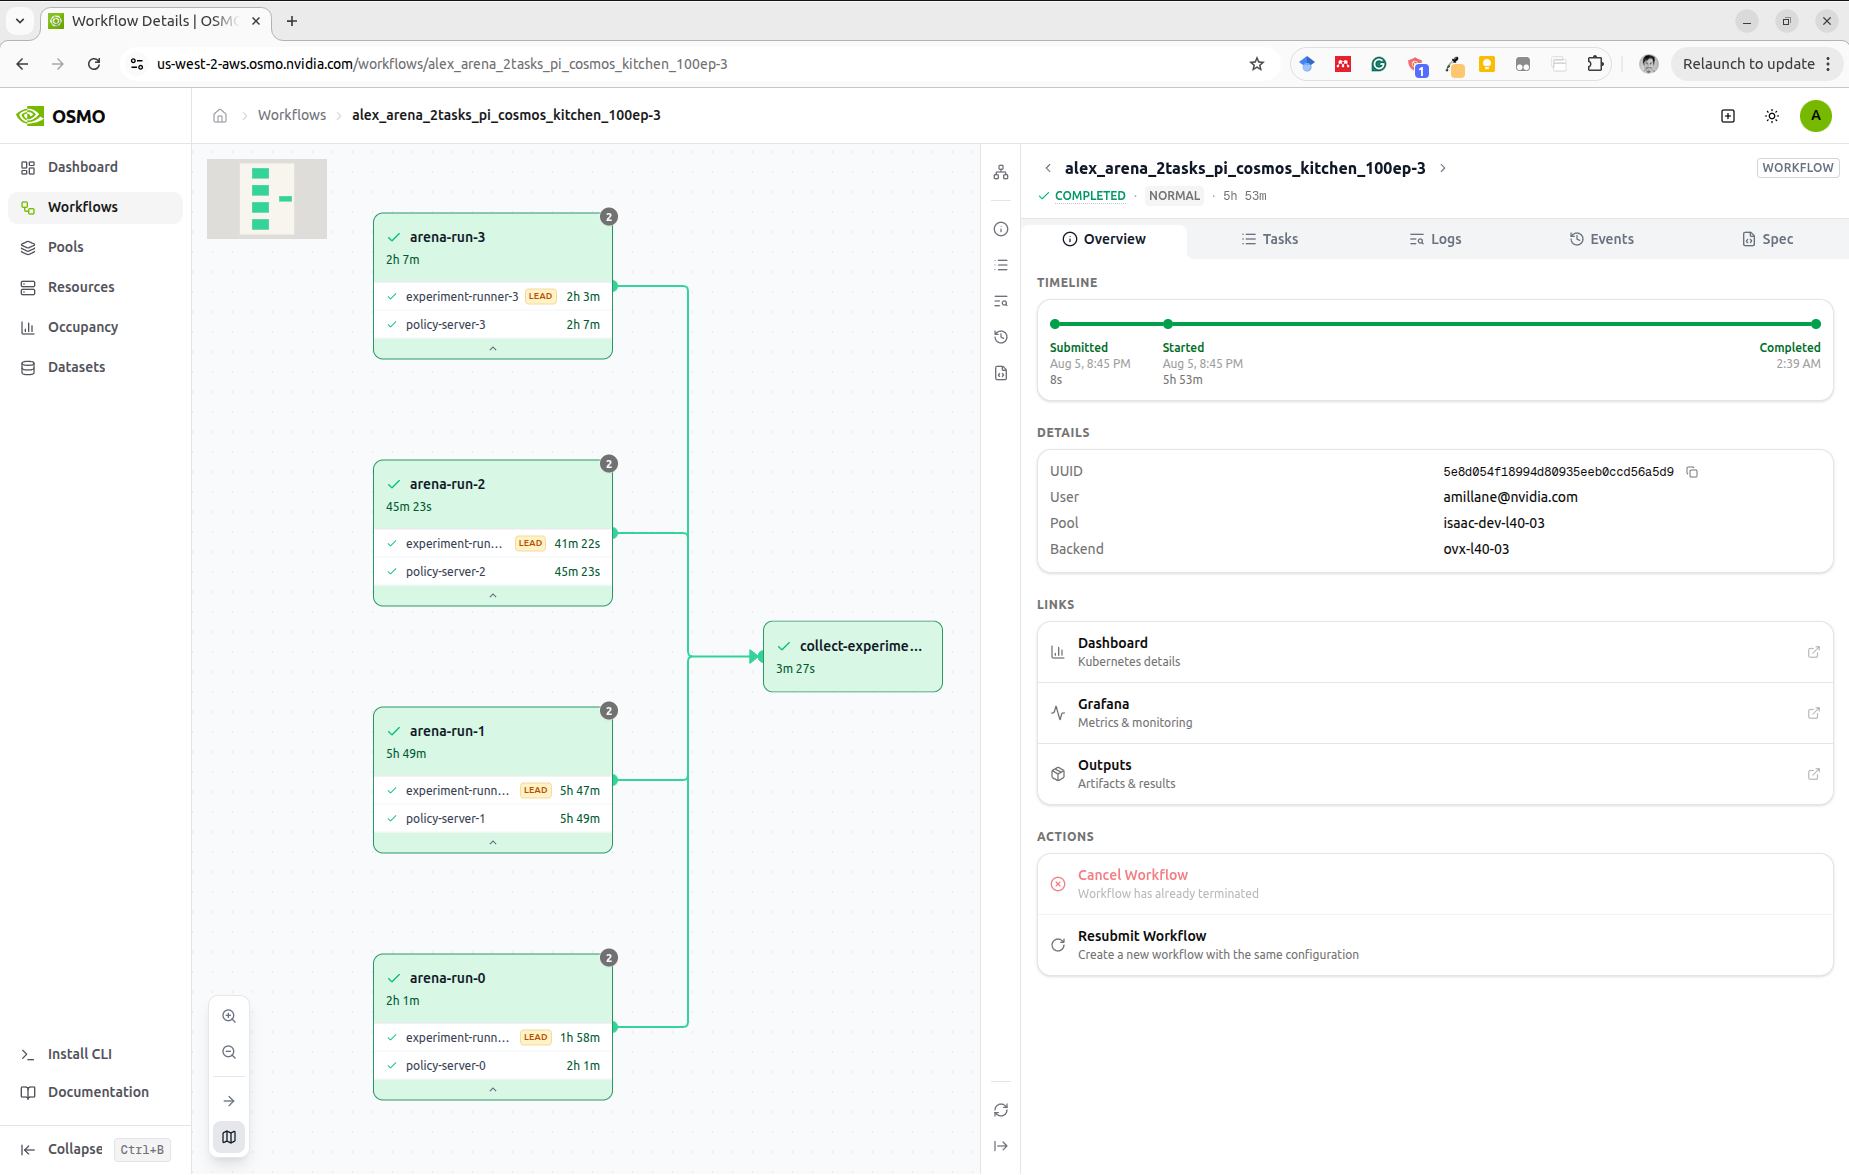
Multi-node Arena evaluation workflow

Scale-out evaluation across multiple compute nodes.#

Sensitivity analysis#
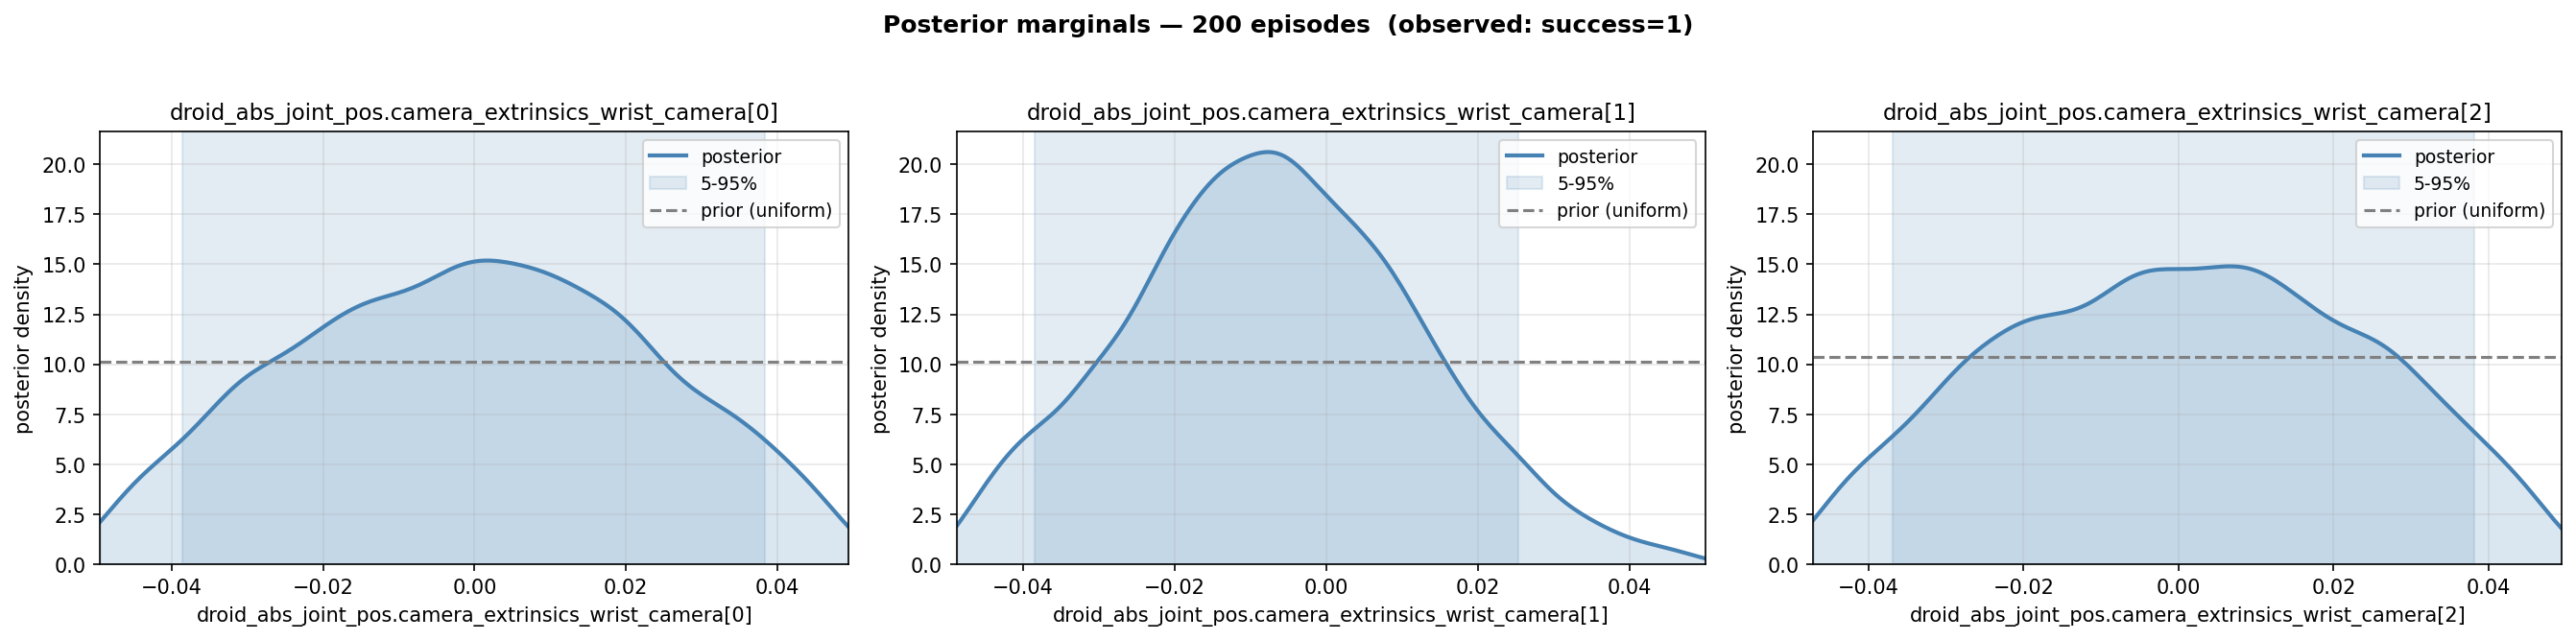
Arena sensitivity analysis report

Analyze which environment factors are associated with policy success or failure.#

previous

Citing Isaac Lab-Arena

next

Development Team Internal

On this page
  • Swappable assets
  • Relational object placement
  • Parallel policy evaluation
  • Agentic environment generation
  • Built-in evaluation environments
  • Environment variations
  • Multi-node evaluation
  • Sensitivity analysis
NVIDIA NVIDIA

Copyright © 2025, NVIDIA.