

Use the Generated Environment#
Once you are satisfied with the environment, you can use it to evaluate a policy on the environment. The base container runs the environment as it was generated. The cuRobo-installed container additionally gates object placement on whether the robot can reach the target objects.
For example, you can use the policy runner to evaluate a PI policy on the environment. For other policy types, see Running a Real Policy.
Open one terminal and run the following command outside the Arena docker container to launch the PI policy server:
./isaaclab_arena_openpi/docker/run_openpi_server.sh
In the other terminal, run the following command to launch the policy runner. The commands below use the
ready-made spec that ships with Arena; to evaluate a spec you generated yourself, point
--env_spec at isaaclab_arena_environments/agent_generated/<env_name>.yaml.
Complete the shared Prerequisites before running this command.
python isaaclab_arena/evaluation/policy_runner.py \
   --viz kit \
   --policy_type isaaclab_arena_openpi.policy.pi0_remote_policy.Pi0RemotePolicy \
   --enable_cameras \
   --num_envs 1 \
   --num_episodes 3 \
   --env_spec isaaclab_arena_environments/maple_table_top/simready_droid_pick_place_cans_hammer_maple_table.yaml
Note
Reachability validation runs only in the cuRobo-installed Docker container
(./docker/run_docker.sh -c). It is not available with a native uv
install — see Installation and
IK Reachability (ik_reachable).
If you want to ensure the robot can reach the target objects (i.e. beverage can, bean can and mini plastic basket), you can use this environment in the cuRobo-installed docker container to activate the reachability validation.
Docker Container: Curobo-installed Base (see Installation for more details)
./docker/run_docker.sh -c
Now only the layouts the robot can reach are used:
python isaaclab_arena/evaluation/policy_runner.py \
   --viz kit \
   --policy_type isaaclab_arena_openpi.policy.pi0_remote_policy.Pi0RemotePolicy \
   --enable_cameras \
   --num_envs 1 \
   --num_episodes 3 \
   --env_spec isaaclab_arena_environments/maple_table_top/simready_droid_pick_place_cans_hammer_maple_table.yaml
While the environment builds, every batch of candidate layouts reports how many of them passed each
check. ik_reachable is the cuRobo verdict, so its ratio is the rejection rate to watch:
[placement] Validated 50 candidate layout(s); passed per check: on_relation=47/50, next_to=39/50, not_next_to=50/50, face_to=50/50, no_overlap=39/50, ik_reachable=6/36
A low ik_reachable ratio means most sampled layouts put the beverage can, bean can, or basket outside the
arm’s workspace, and the placer keeps resampling. A composite task rejects more layouts than an atomic
one, because every pick target and the place target must be reachable in the same layout.
When an environment finds no reachable layout at all, it falls back to its lowest-loss layout.
See IK Reachability (ik_reachable) for how this check is registered, what it requires, and how to tune or disable it.
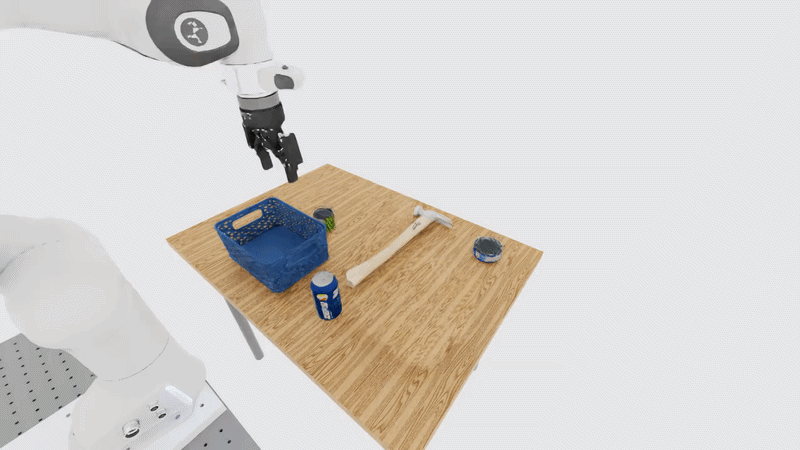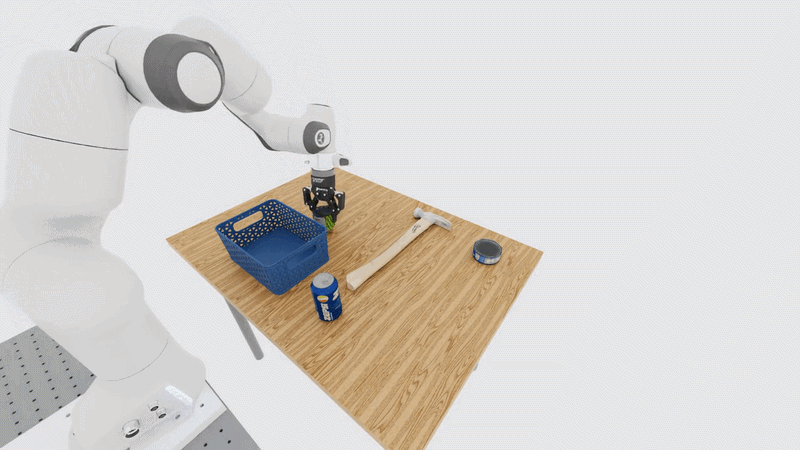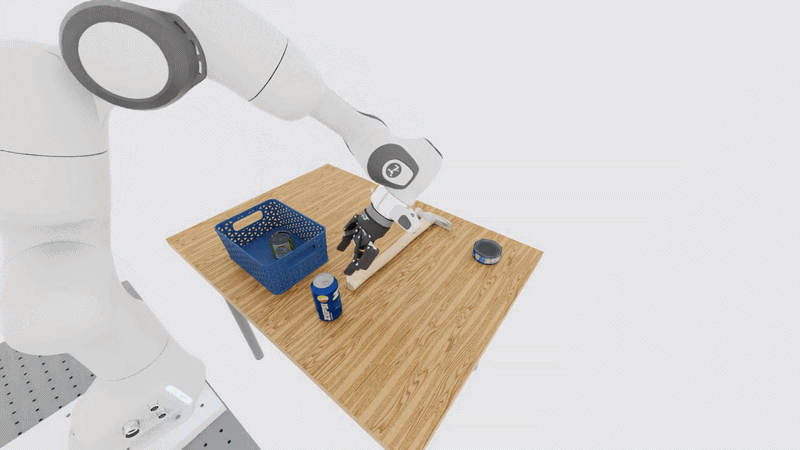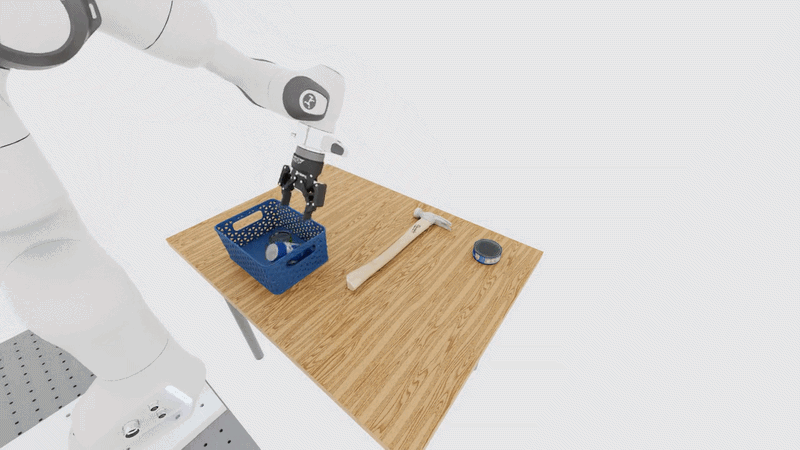
Policy evaluation of the generated environment using the OpenPI policy with reachability validation. The robot picks up the beverage can and bean can and places them into the mini plastic basket.#