

Edit the Environment Graph Spec#
You may want to review or edit the spec before building the environment. The agent infers the spec from the prompt using a LLM model, and could be mistaken in its choices. For a kitchen scene, the two edits that matter most are which countertop prim the task uses and where the robot stands.
Understanding the YAML#
The generated spec has one block per part of the environment graph:
env_name: kitchen_bench_lightwheel_pick_and_place
embodiment:                       # the robot, from the embodiment registry
  id: droid
  registry_name: droid_abs_joint_pos
  params:
    stand_height_m: 0.8           # the stand that lifts DROID to counter height
background:                       # the kitchen the task happens in
  id: kitchen
  registry_name: lightwheel_kitchen_one_wall_coastal
  params: {}
objects:                          # assets spawned into the scene
- id: mustard_bottle              # the pick target
  registry_name: mustard_bottle_hope_robolab
  params: {}
- id: bowl                        # the placement destination
  registry_name: bowl_ycb_robolab
  params: {}
object_references:                # prims that already exist inside the background
- id: right_counter_top
  parent_id: kitchen
  prim_path: counter_main_main_group/top_geometry_right
  object_type: base
  params: {}
- id: floor
  parent_id: kitchen
  prim_path: floor_room/geometry
  object_type: base
  params: {}
relations:                        # spatial constraints solved at build time
- kind: is_anchor                 # referenced prims stay where the kitchen puts them
  subject: floor
  params: {}
- kind: is_anchor
  subject: right_counter_top
  params: {}
- kind: 'on'                      # the robot stands on the kitchen floor
  subject: droid
  reference: floor
  params: {}
- kind: next_to
  subject: droid
  reference: right_counter_top
  params:
    side: negative_y
    distance_m: 0.15
- kind: rotate_around_solution    # turn the robot to face the counter
  subject: droid
  params:
    yaw_rad: 1.57
- kind: 'on'                      # every object needs its own placement relation
  subject: mustard_bottle
  reference: right_counter_top
  params: {}
- kind: 'on'
  subject: bowl
  reference: right_counter_top
  params: {}
task:
  composition: atomic             # a single task
  description: pick up the mustard bottle and place it in the bowl
  subtasks:
  - kind: PickAndPlaceTask
    params:
      pick_up_object: mustard_bottle   # object id, not registry name
      destination_location: bowl
      background_scene: kitchen
An object_references entry is a prim that the background already contains, addressed by its
prim_path under parent_id. Nothing is spawned for it — it only becomes a target that relations and
task params can name by id, exactly like a spawned object.
For more details on the Env Spec, see Environment Definition.
Resolving the countertop ambiguity#
The prompt does not identify which countertop to use, and the kitchen contains five candidate counter
surfaces. List them from the background prim tree — the set of prims the agent itself chooses
prim_path from — either in the GUI or from the command line:
Expand the GUI’s Background prim tree and search for counter:
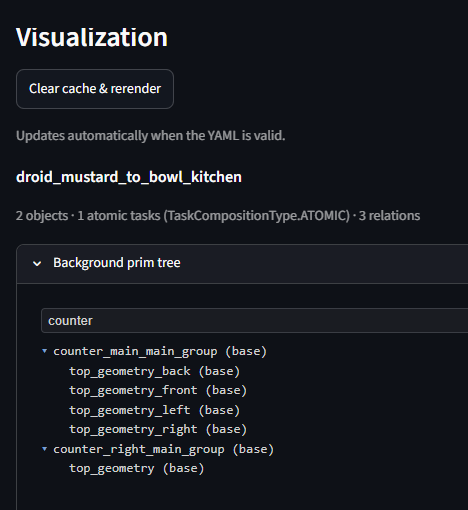
The background prim tree disambiguates the counter surfaces available in the Lightwheel RoboCasa kitchen.#
The prim tree can be read from the background USD with the runner in prim_tree mode:
python isaaclab_arena_examples/agentic_environment_generation/cli_runner.py \
   --mode prim_tree \
   --env_spec isaaclab_arena_environments/kitchen_bench/kitchen_bench_lightwheel_pick_and_place.yaml \
   | grep counter
It prints each line as a prim_path candidate with its object_type, plus the joint names when the prim
is an articulation.
counter_main_main_group  object_type=base
counter_main_main_group/top_geometry_back  object_type=base
counter_main_main_group/top_geometry_front  object_type=base
counter_main_main_group/top_geometry_left  object_type=base
counter_main_main_group/top_geometry_right  object_type=base
counter_right_main_group  object_type=base
counter_right_main_group/top_geometry  object_type=base
For this task, select the center-right countertop by updating the object reference in the spec:
object_references:
- id: right_counter_top
  parent_id: kitchen
  prim_path: counter_main_main_group/top_geometry_right
  object_type: base
  params: {}
Refining the robot placement#
The generated relations identify the correct entities, but the initial layout
may place the robot on the wrong side of the counter or facing the wrong
direction. Set the next_to parameters manually and add a
rotate_around_solution relation to rotate the robot to face the counter:
- kind: next_to
  subject: droid
  reference: right_counter_top
  params:
    side: negative_y
    distance_m: 0.15
- kind: rotate_around_solution
  subject: droid
  params:
    yaw_rad: 1.57
Applying your edits#
The GUI is the recommended way to make these edits, because it validates and previews as you type:
Edit the spec directly in the YAML editor panel.
Click Clear cache and render to update the visualization of the environment graph.
Click Run relation solver preview to build the environment, solve the relations, run a zero-action rollout, and compare the viewport before and after the relation solver is run.
Click Save to <env_name>.yaml to write the spec to
<env_name>.yamlin the output directory.
See GUI Runner for the full UI walkthrough.
The YAML written by the CLI runner is locally stored so you can also edit it in any text editor and validate it by building and spawning a simulation environment:
python isaaclab_arena_examples/agentic_environment_generation/cli_runner.py \
   --mode build \
   --viz kit \
   --num_envs 1 \
   --num_steps 100 \
   --env_spec isaaclab_arena_environments/kitchen_bench/kitchen_bench_lightwheel_pick_and_place.yaml
A spec you generated yourself is written to
isaaclab_arena_environments/agent_generated/<env_name>.yaml instead — pass that path to build it.