

Run Agentic Environment Generation#
Complete the shared Prerequisites before running this workflow.
The Arena environment generation agent infers an ArenaEnvGraphSpec YAML from a user prompt.
The agent runs in two modes:
GUI runner — a browser live editor. Generate from a prompt, then edit, visualize, and simulation-preview the spec in the same session.
CLI runner — a one-shot, non-interactive pipeline. It writes the YAML and editing can be done manually in a text editor. Use it for scripted or batch generation.
Name the background prims the task depends on — the counter top and the floor — so the agent emits them as
object_references instead of spawning new assets. Also describe where the robot stands, because in a
kitchen the robot is placed in the scene rather than mounted on the task surface.
Note
We recommend the GUI runner for this workflow because it takes interactive editing to disambiguate the countertop and refine the robot placement.
Start the live editor and open http://localhost:8501 in a browser:
python isaaclab_arena_examples/agentic_environment_generation/gui_runner.py
In the Generate from prompt panel, enter the prompt and click
Generate spec:
There is a counter top in the lightwheel_kitchen_one_wall_coastal background.
DROID picks up a mustard bottle on the counter top and places it in a bowl.
The generated environment graph contains the kitchen, the mustard bottle, the bowl, and a reference to a counter surface, but no placement for the robot itself.
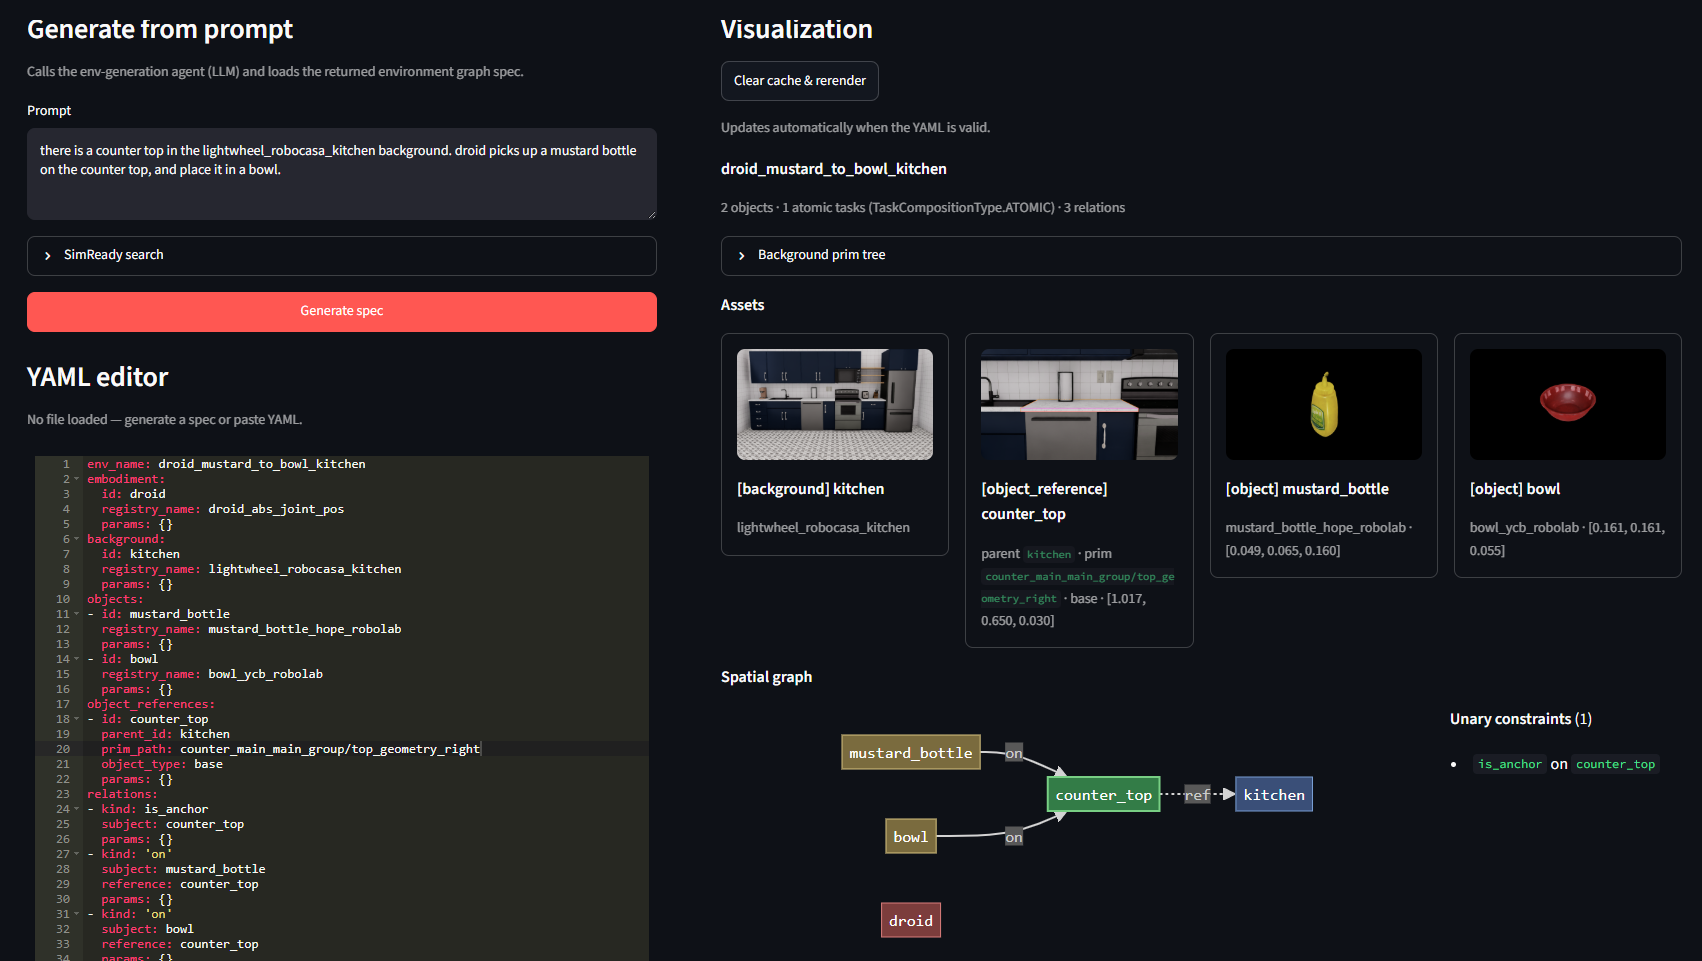
The first prompt generates the object placement and the pick-and-place task.#
Replace the prompt with one that also describes the robot placement and regenerate:
There is a center-right counter top and a floor in the
lightwheel_kitchen_one_wall_coastal background. DROID picks up a mustard bottle on
the counter top and places it in a bowl. DROID is next to the counter top
and on the floor.
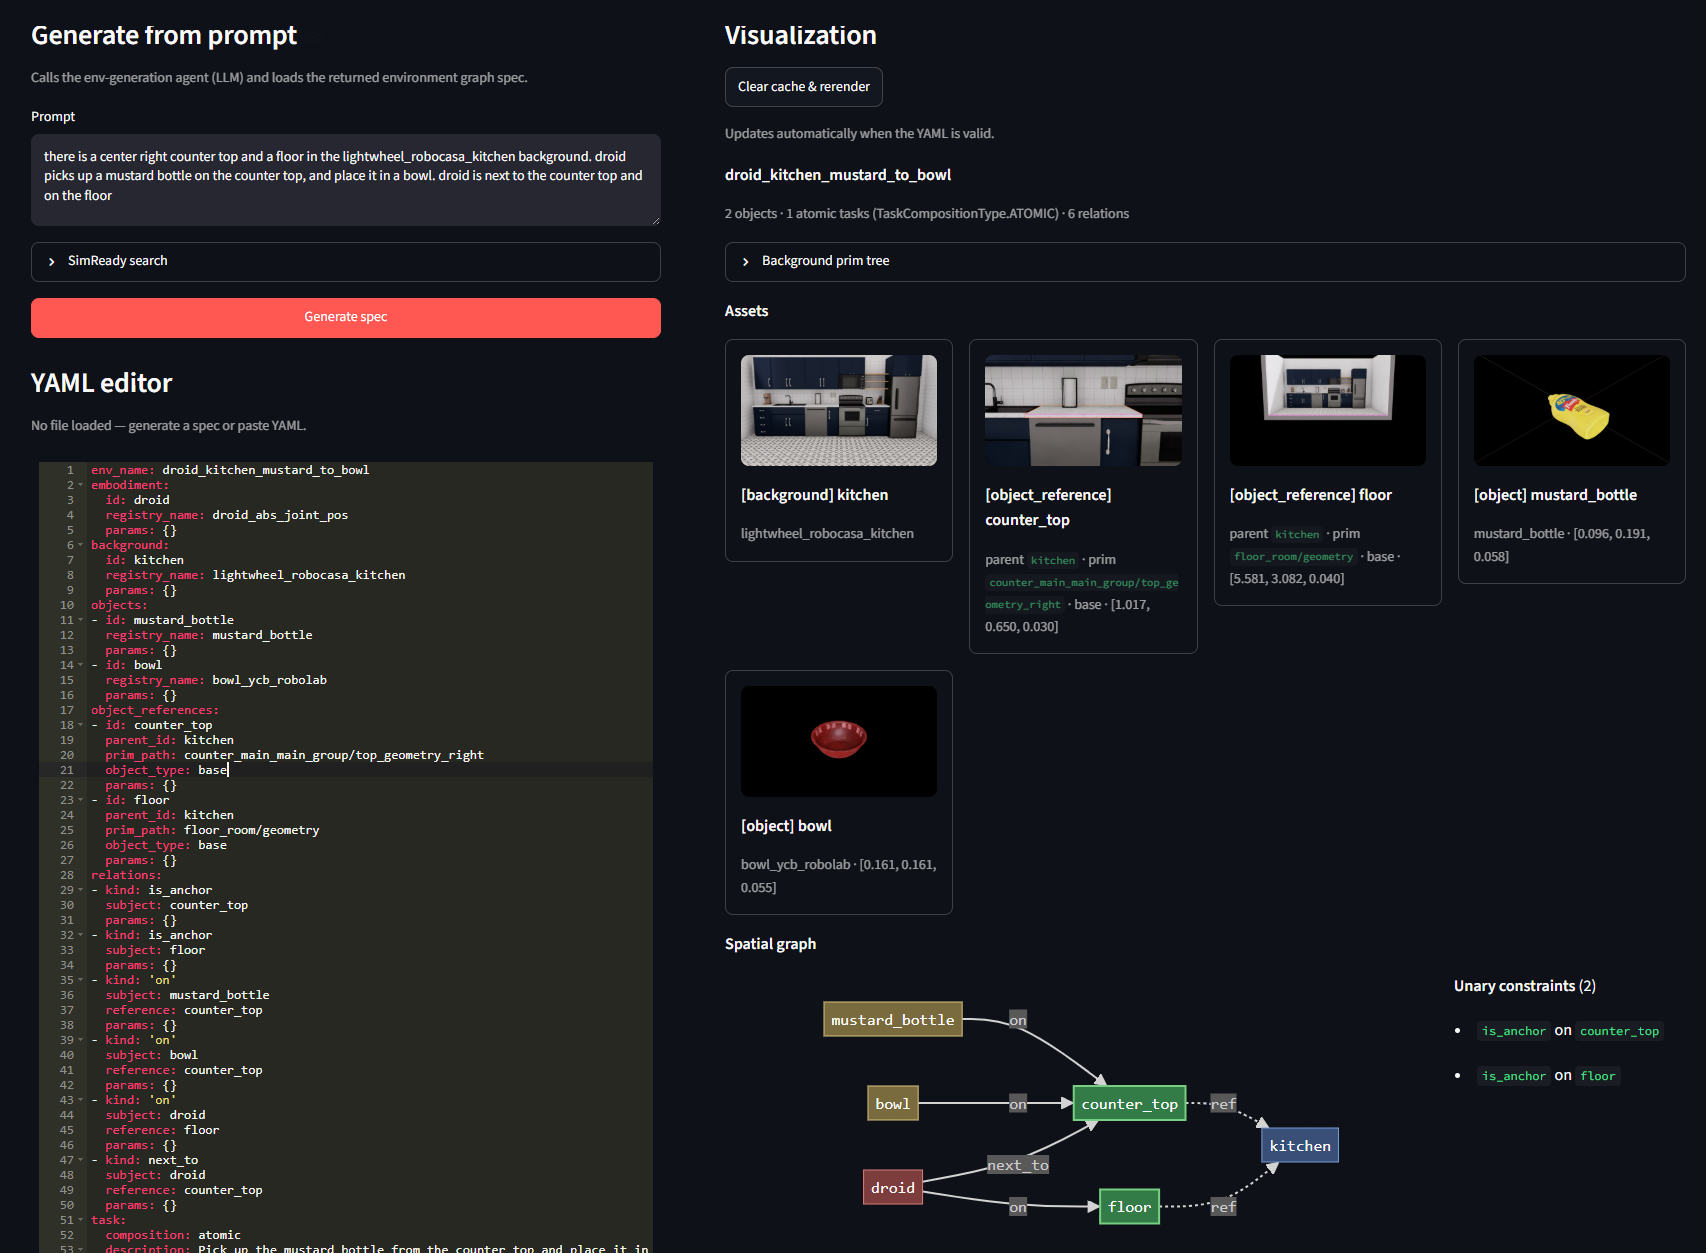
The second prompt adds the floor reference and the DROID on and next_to relations.#
Run the runner in resolve mode:
python isaaclab_arena_examples/agentic_environment_generation/cli_runner.py \
   --mode resolve \
   --prompt "There is a center-right counter top and a floor in the lightwheel_kitchen_one_wall_coastal background. DROID picks up a mustard bottle on the counter top and places it in a bowl. DROID is next to the counter top and on the floor."
The runner prints the generated graph and writes <env_name>.yaml under
isaaclab_arena_environments/agent_generated/.